From Fusion 360 to a ROS 2 Digital Twin: URDF, RViz and Gazebo That Match the Real Arm (OmArm One Part 2)
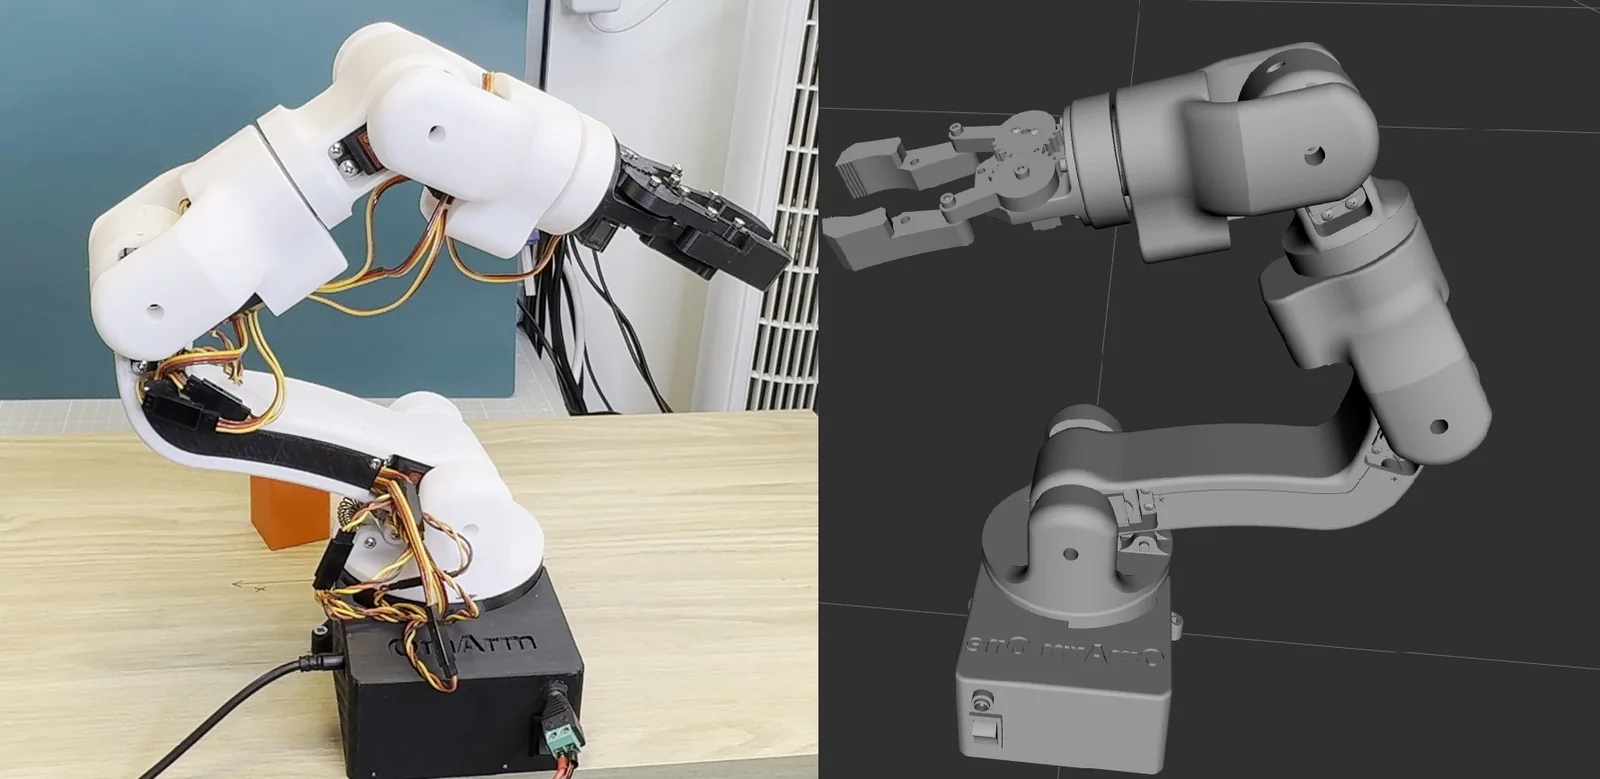
The real 3D printed OmArm One robot arm on a workbench beside the same arm rendered in RViz, both in the same pose

Export a URDF from Fusion 360, audit it, correct joint directions, zeros and limits so the model matches the real OmArm One, and run it in RViz and Gazebo Harmonic. Part 2 of the OmArm One series, with the free ROS 2 Jazzy package.
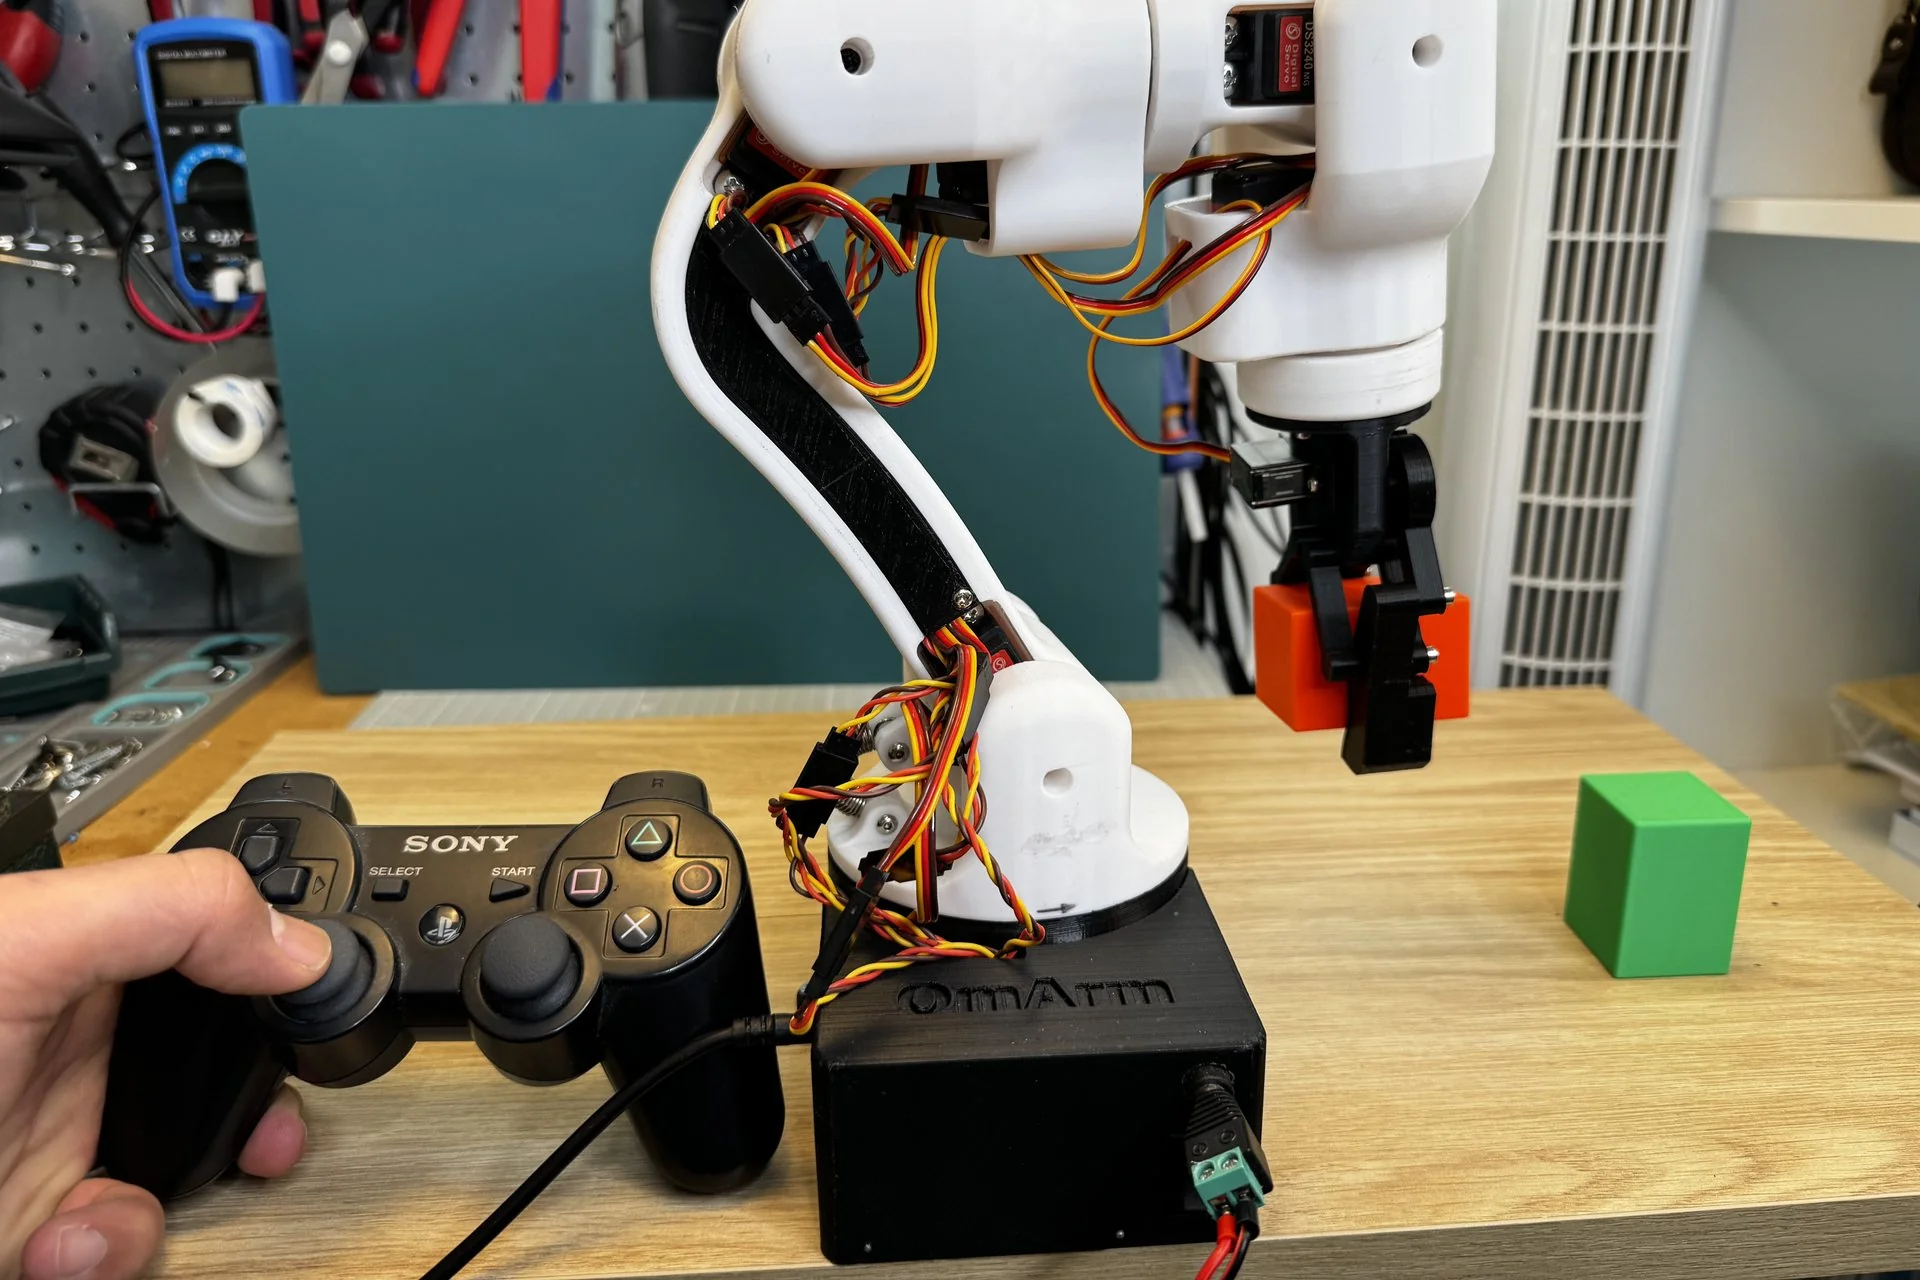
Drive a 3D Printed Robot Arm with a PS3 Controller: ESP32, Bluetooth, No PC (OmArm One Part 1.5)

A DualShock 3 controller held in one hand with the 3D printed OmArm One robot arm behind it holding an orange cube

Pair a PS3 controller to an ESP32 with Bluepad32 and drive a 3D printed 6-DOF robot arm: velocity sticks, four speed levels, a recorded pose sequence and a latching stop, with no PC in the loop.

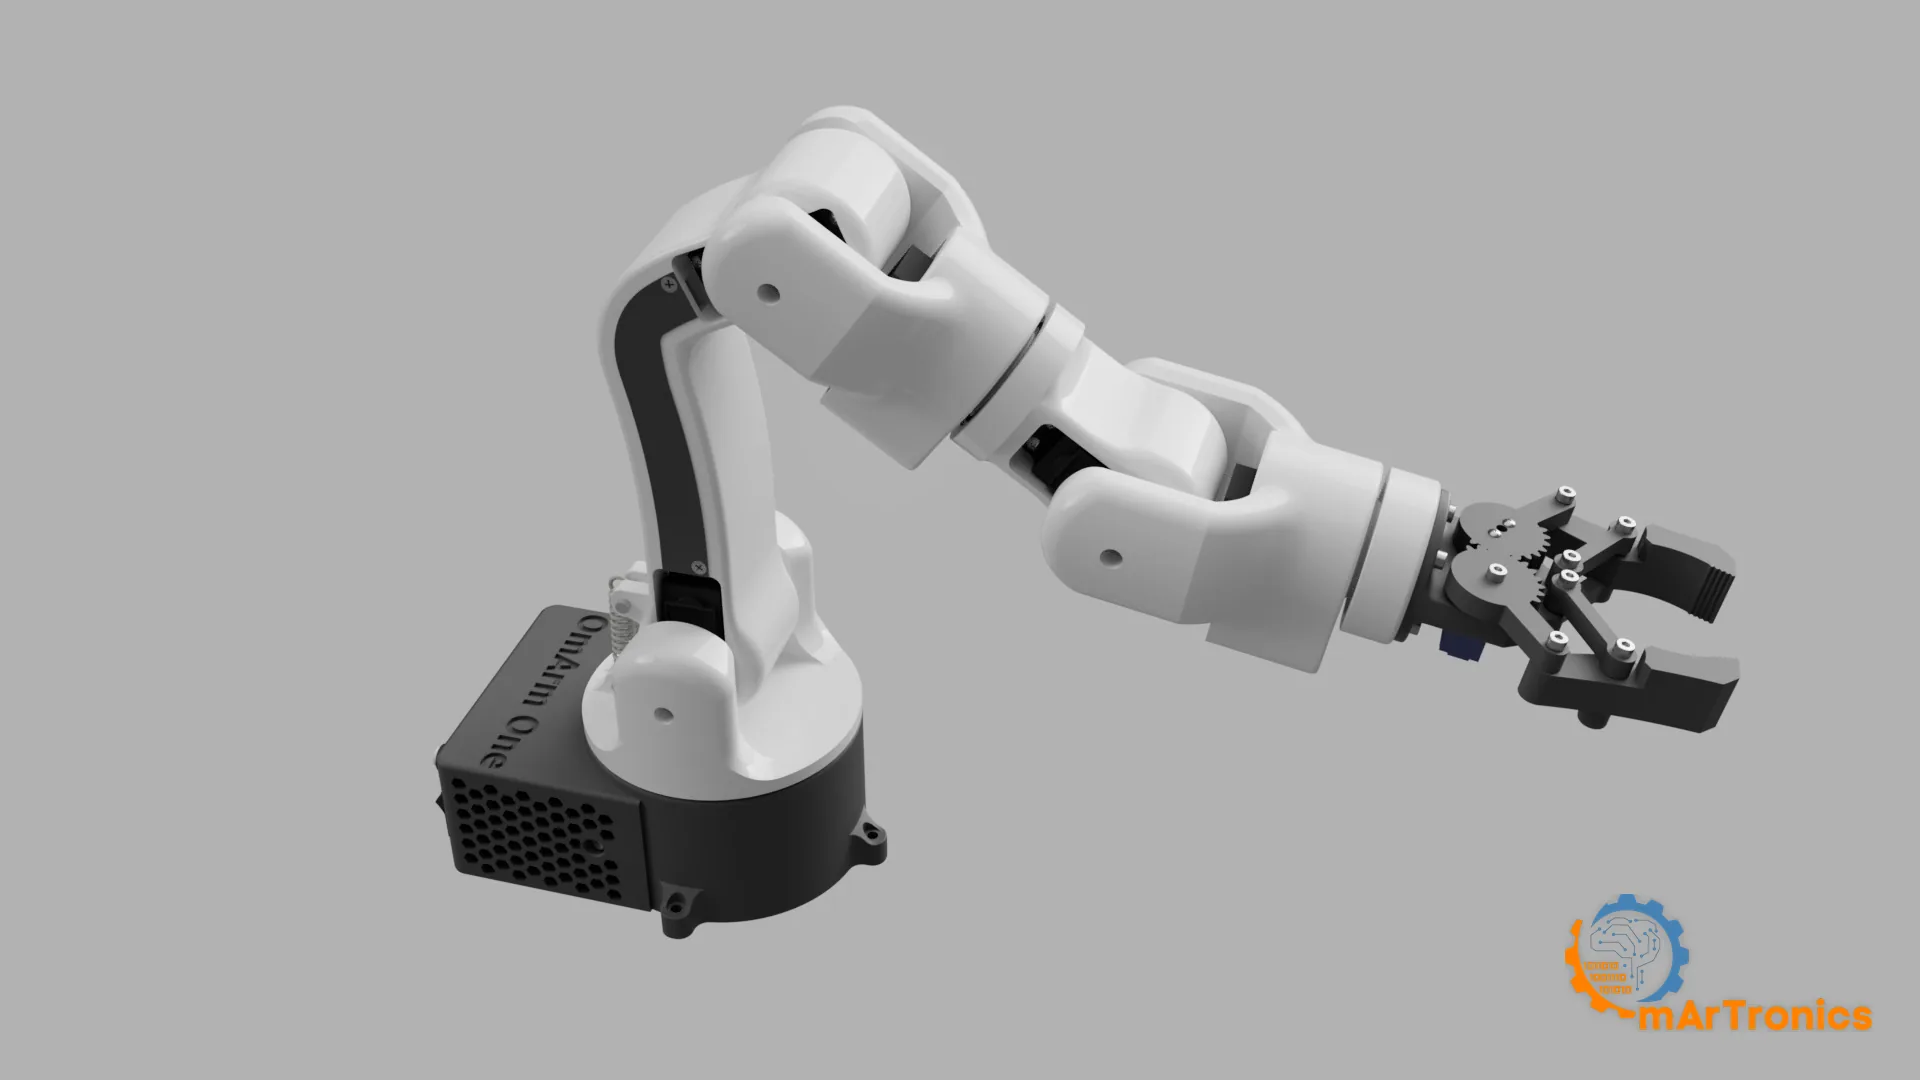
OmArm One: Build a 3D Printed 7-DOF Robot Arm on Real Ball Bearings (Part 1)

OmArm One, a 6-joint printed arm with a parallel-jaw gripper, rendered from the CAD assembly

Build a 3D printed robot arm with 7 DOF on real ball bearings: 485 mm reach, 200 g payload, full BOM, 16 assembly animations and ESP32 web control.

Building a Line Following Robot with TCS34725 RGB Sensor

A 3D-rendered line-following robot designed with an orange and blue chassis, featuring OmArTronics branding, two wheels, and a support caster wheel, suitable for DIY robotics projects.

Complete tutorial for building an advanced TCS34725 line-following robot with Arduino and PID control. Covers 3D chassis design, wiring, sensor calibration, PID tuning, and full code walkthrough. The natural upgrade from the beginner KY-033 line follower project.

Building a Line Following Robot with KY-033 Sensors for Beginners

A 3D-rendered line-following robot designed with an orange and blue chassis, featuring OmArTronics branding, two wheels, and a support caster wheel, suitable for DIY robotics projects.

Learn how to build a KY-033 line following robot with Arduino from scratch. This beginner tutorial covers 3D design, assembly, wiring, Arduino code, testing, tuning, and troubleshooting for a complete DIY line follower robot project.

OmObiArm: Building a Mobile Robot with an Integrated Robotic Arm Using Arduino and Bluetooth Control

Mobile robot arm OmObiArm with an orange gripper and four wheels on a white chassis, Bluetooth-controlled and designed using Arduino.

Build OmObiArm, a DIY Bluetooth-controlled mobile robot arm powered by Arduino Mega, HC-05, Adafruit Motor Shield, and PCA9685 servo driver. Complete tutorial covering 3D design, assembly, wiring, Arduino code, MIT App Inventor app, calibration, troubleshooting, and FAQ.

Building an Advanced Autonomous and Bluetooth-Controlled Robot Car with Arduino Mega, Ultrasonic Sensors, and Adafruit Motor Shield

Advanced autonomous and remote-controlled robot car equipped with Arduino Mega and sensors.

Build an advanced autonomous robot car with Arduino Mega, four HC-SR04 ultrasonic sensors, HC-05 Bluetooth, and Adafruit Motor Shield. This step-by-step tutorial covers chassis assembly, wiring, Arduino code, an MIT App Inventor control app, and autonomous obstacle avoidance.

L298N Motor Driver with Arduino: DC Motor Control Guide

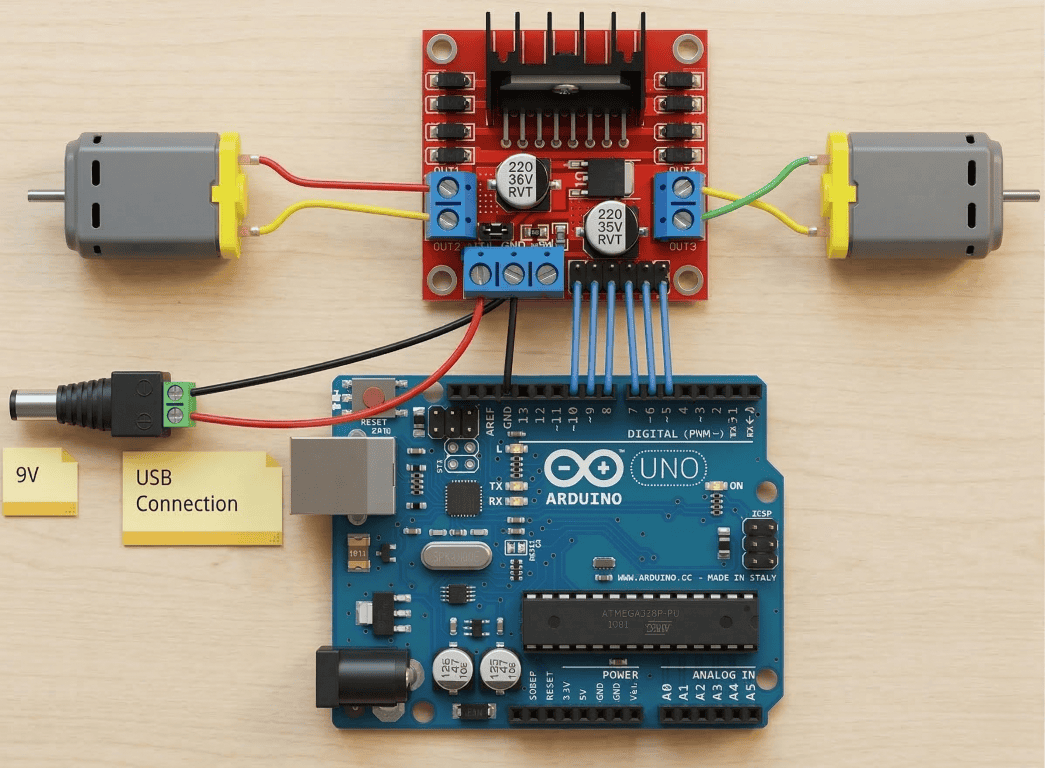
Realistic wiring diagram of an L298N motor driver module connected to an Arduino Uno and two DC motors for controlling direction and speed.

The L298N is a dual H-bridge motor driver, and it is one of the most common ways to control DC motors with an Arduino. Here I go through the pinout, how to wire it up, how PWM speed control actually works, and how to set motor direction in code. There is also a troubleshooting section for the issues that tend to come up.