MoveIt 2 on a Real Robot Arm: ros2_control, Inverse Kinematics and a URDF That Matches the Hardware (OmArm One Part 3)
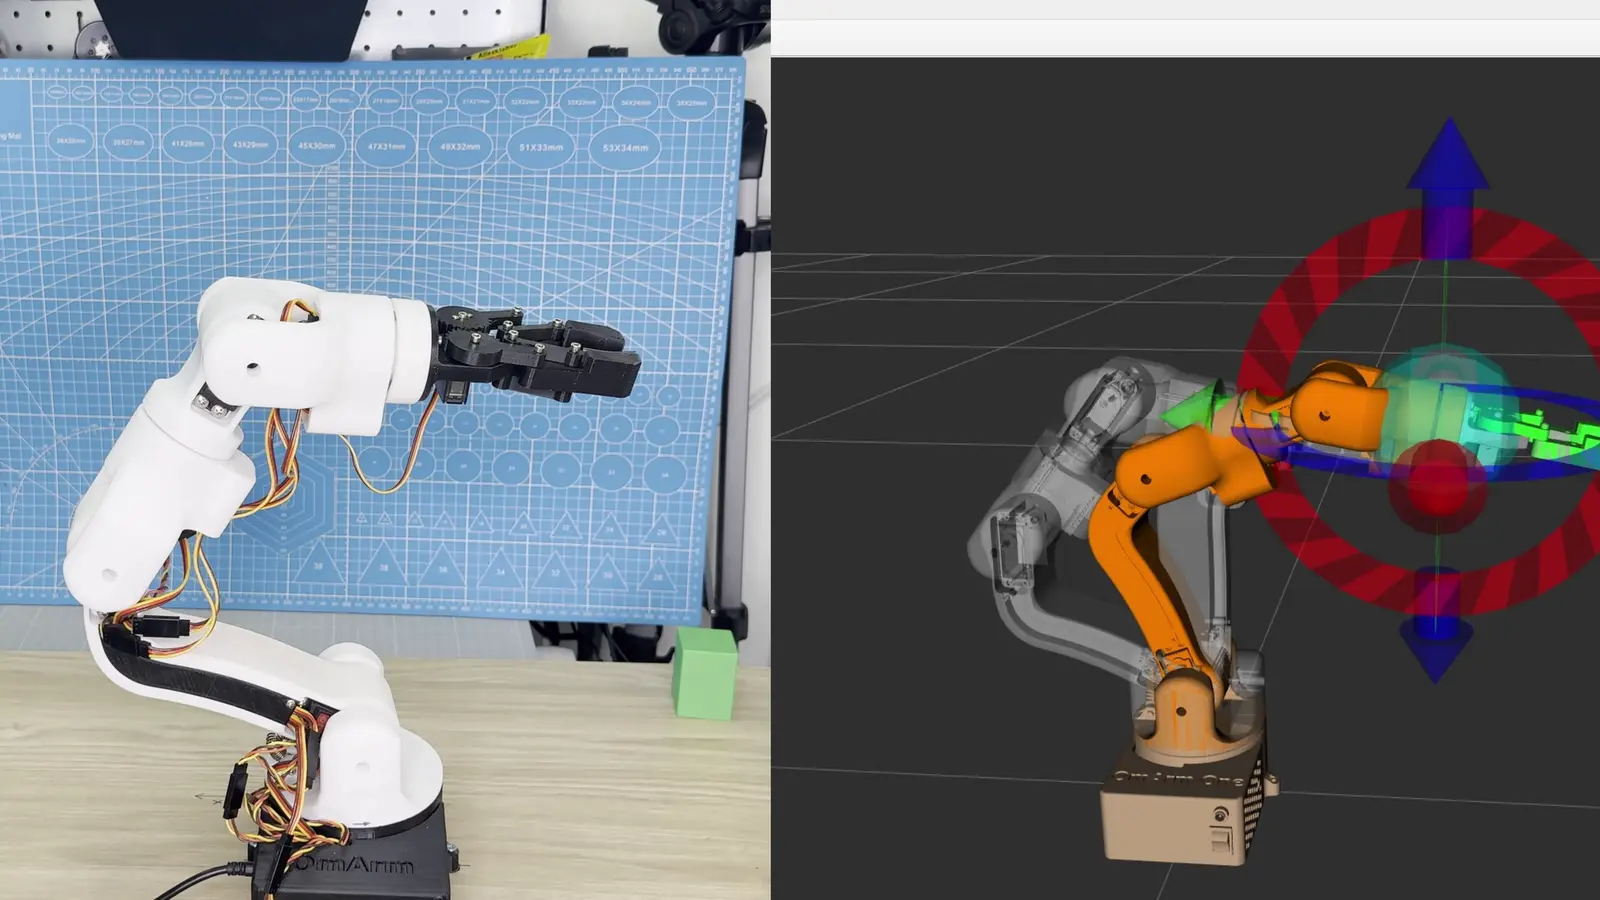
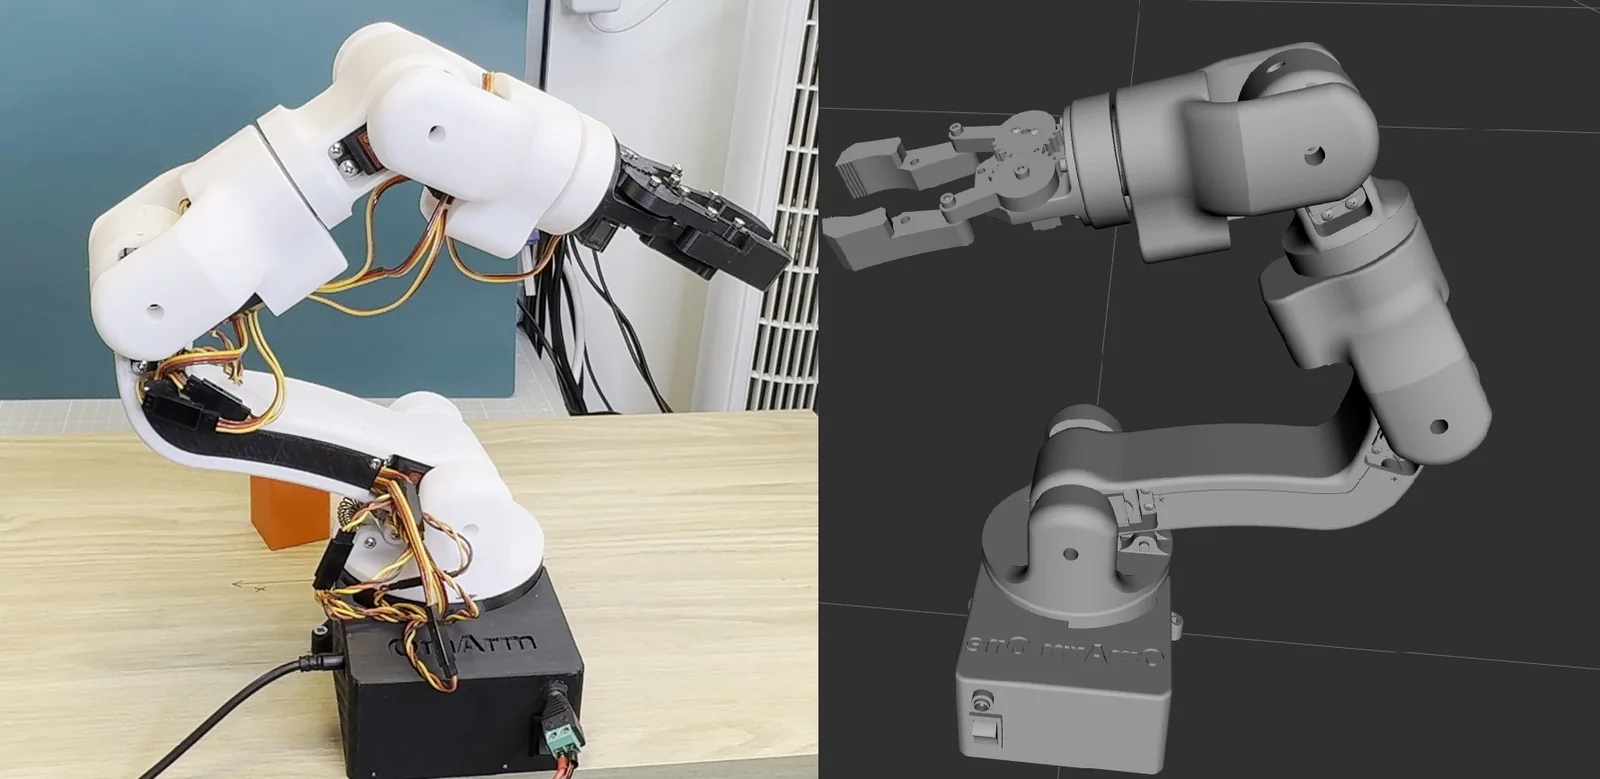
The real OmArm One and its RViz model in the same pose, with the interactive marker on the gripper

MoveIt 2 on a real robot arm with ROS 2 Jazzy: audit the CAD export against the built arm, set up ros2_control, derive the inverse kinematics, build the MoveIt package with the Setup Assistant and drive an ESP32 arm over one USB cable.
From Fusion 360 to a ROS 2 Digital Twin: URDF, RViz and Gazebo That Match the Real Arm (OmArm One Part 2)

The real 3D printed OmArm One robot arm on a workbench beside the same arm rendered in RViz, both in the same pose

Export a URDF from Fusion 360, audit it, correct joint directions, zeros and limits so the model matches the real OmArm One, and run it in RViz and Gazebo Harmonic. Part 2 of the OmArm One series, for ROS 2 Jazzy.

Drive a 3D Printed Robot Arm with a PS3 Controller: ESP32, Bluetooth, No PC (OmArm One Part 1.5)

A DualShock 3 controller held in one hand with the 3D printed OmArm One robot arm behind it holding an orange cube

Pair a PS3 controller to an ESP32 with Bluepad32 and drive a 3D printed 7-DOF (6+1 gripper) robot arm: velocity sticks, four speed levels, a recorded pose sequence and a latching stop, with no PC in the loop.

OmArm One: Build a 3D Printed 7-DOF Robot Arm on Real Ball Bearings (Part 1)

OmArm One, a 6-joint printed arm with a parallel-jaw gripper, rendered from the CAD assembly

Build a 3D printed robot arm with 7 DOF on real ball bearings: 485 mm reach, 200 g payload, full BOM, 16 assembly animations and ESP32 web control.