MoveIt 2 on a Real Robot Arm: ros2_control, Inverse Kinematics and a URDF That Matches the Hardware (OmArm One Part 3)
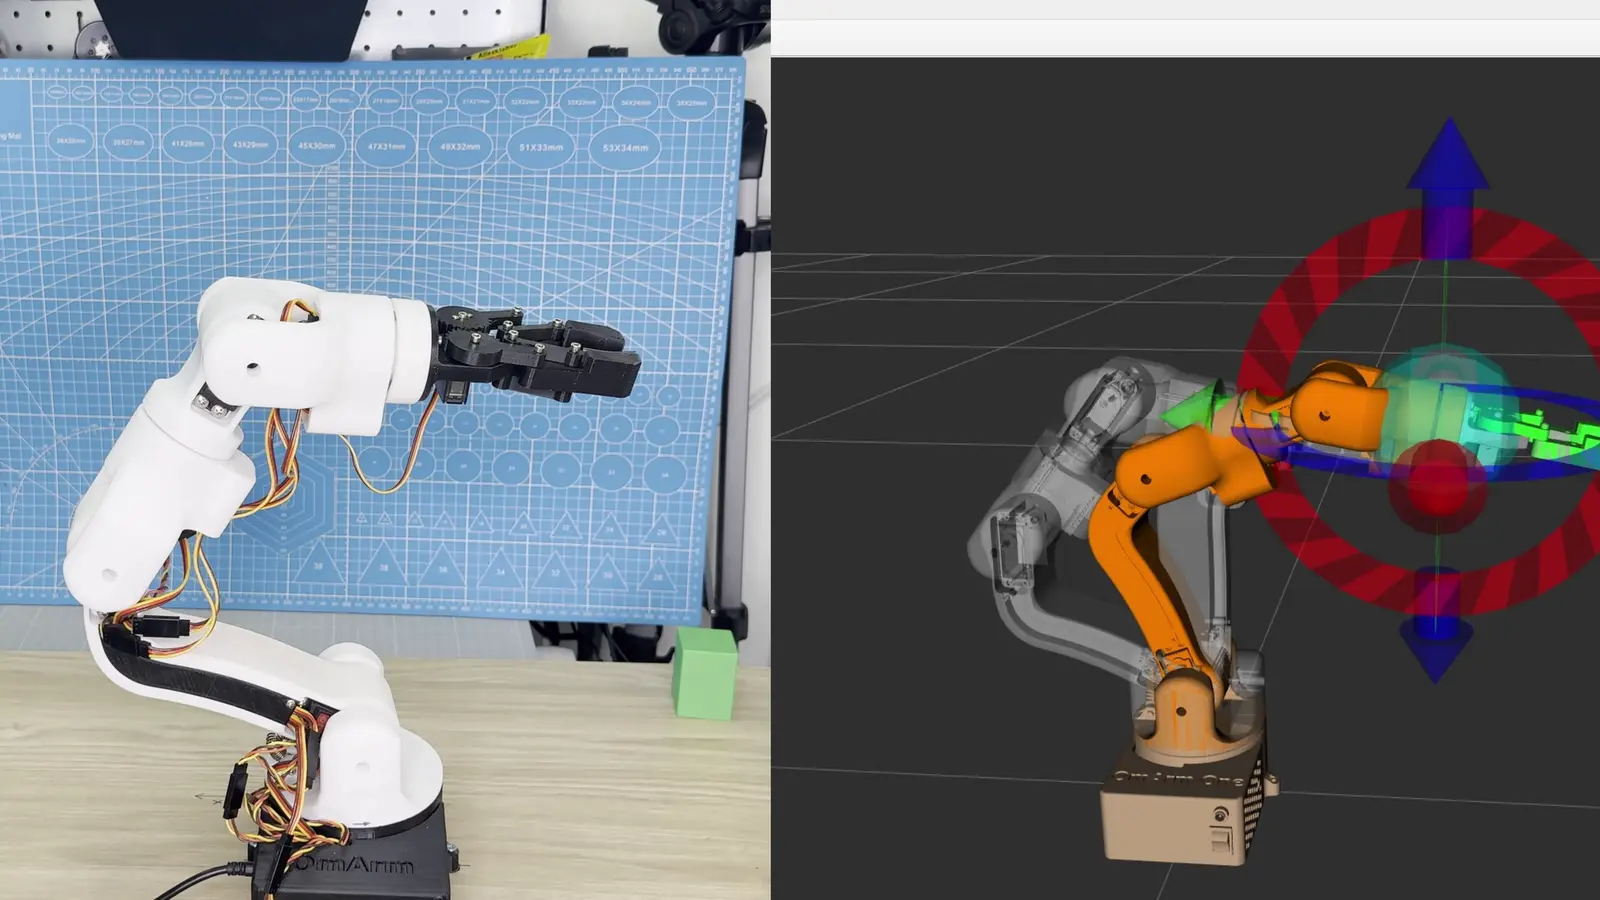
MoveIt 2 on a real robot arm with ROS 2 Jazzy: audit the CAD export against the built arm, set up ros2_control, derive the inverse kinematics, build the MoveIt package with the Setup Assistant and drive an ESP32 arm over one USB cable.