From Fusion 360 to a ROS 2 Digital Twin: URDF, RViz and Gazebo That Match the Real Arm (OmArm One Part 2)
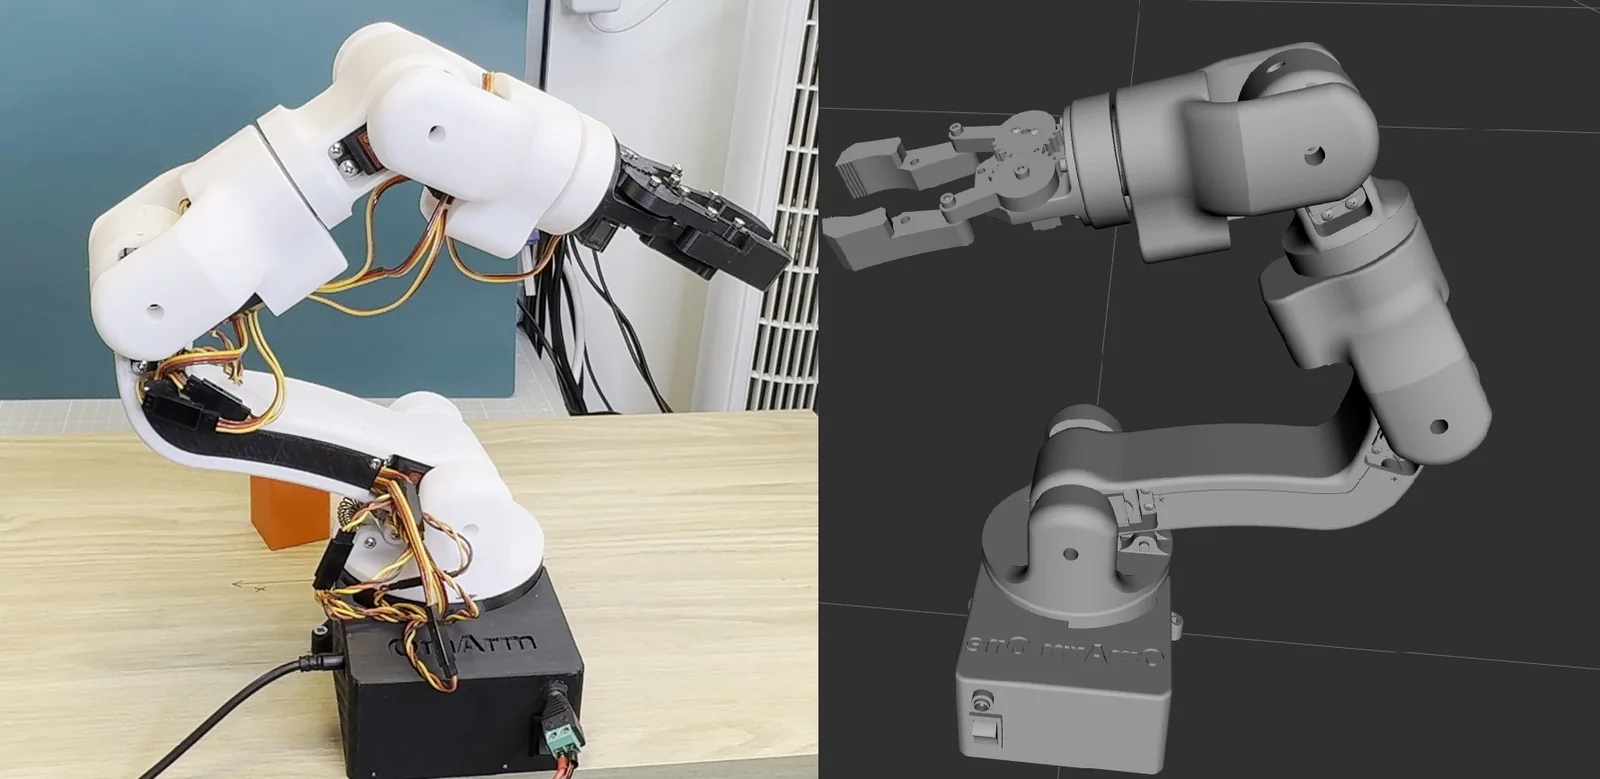
The real 3D printed OmArm One robot arm on a workbench beside the same arm rendered in RViz, both in the same pose

Export a URDF from Fusion 360, audit it, correct joint directions, zeros and limits so the model matches the real OmArm One, and run it in RViz and Gazebo Harmonic. Part 2 of the OmArm One series, with the free ROS 2 Jazzy package.
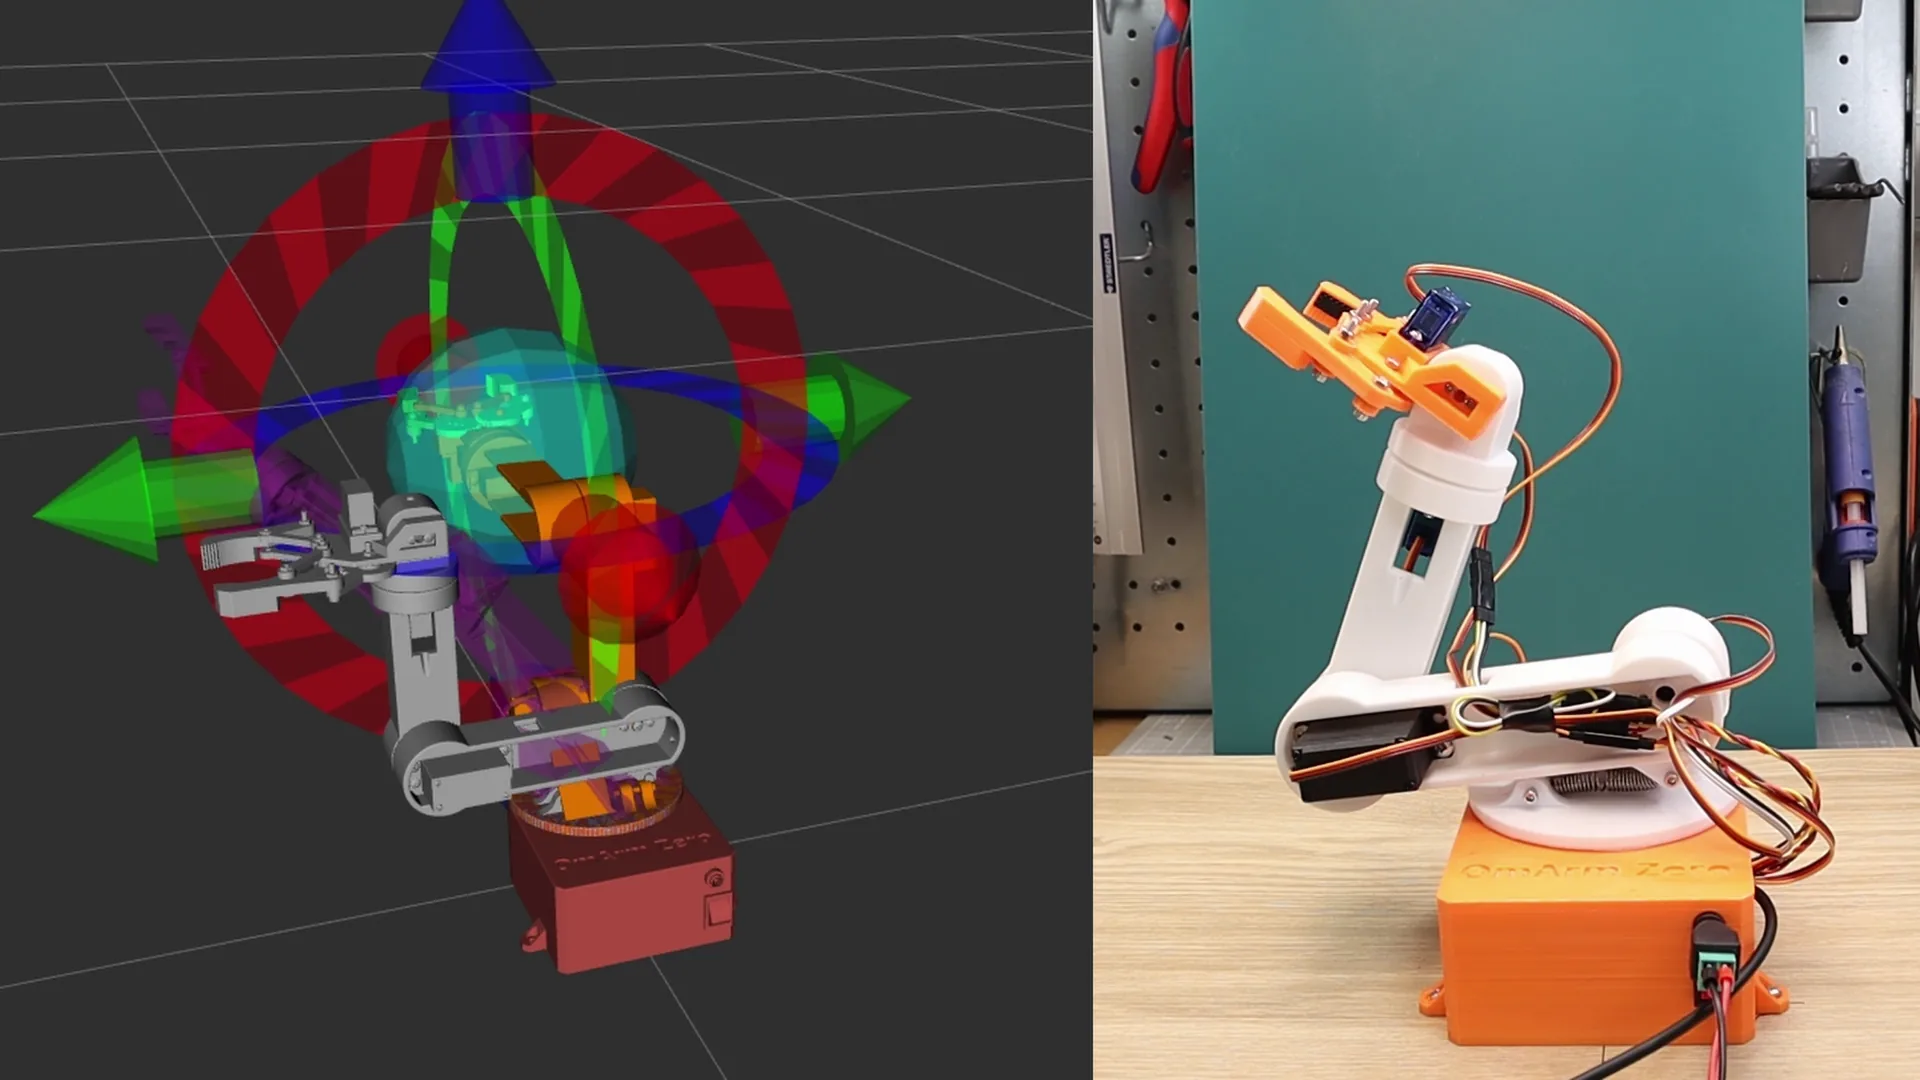
MoveIt 2 Tutorial: Motion Planning and Real Robot Control for a 6-DOF Arm

OmArm Zero robot arm with MoveIt 2 motion planning visualization in RViz

OmArm Zero Series Part 1: Build · Part 2: URDF + RViz + Gazebo · Part 3: MoveIt 2 (this post) · Part 4: Computer Vision Pick-and-Place ▶ At a glance What you’ll build: A fully configured MoveIt 2 setup for the OmArm Zero robot arm. You’ll go from understanding inverse kinematics to planning collision-free … Read more