
From Fusion 360 to a ROS 2 Digital Twin: URDF, RViz and Gazebo That Match the Real Arm (OmArm One Part 2)
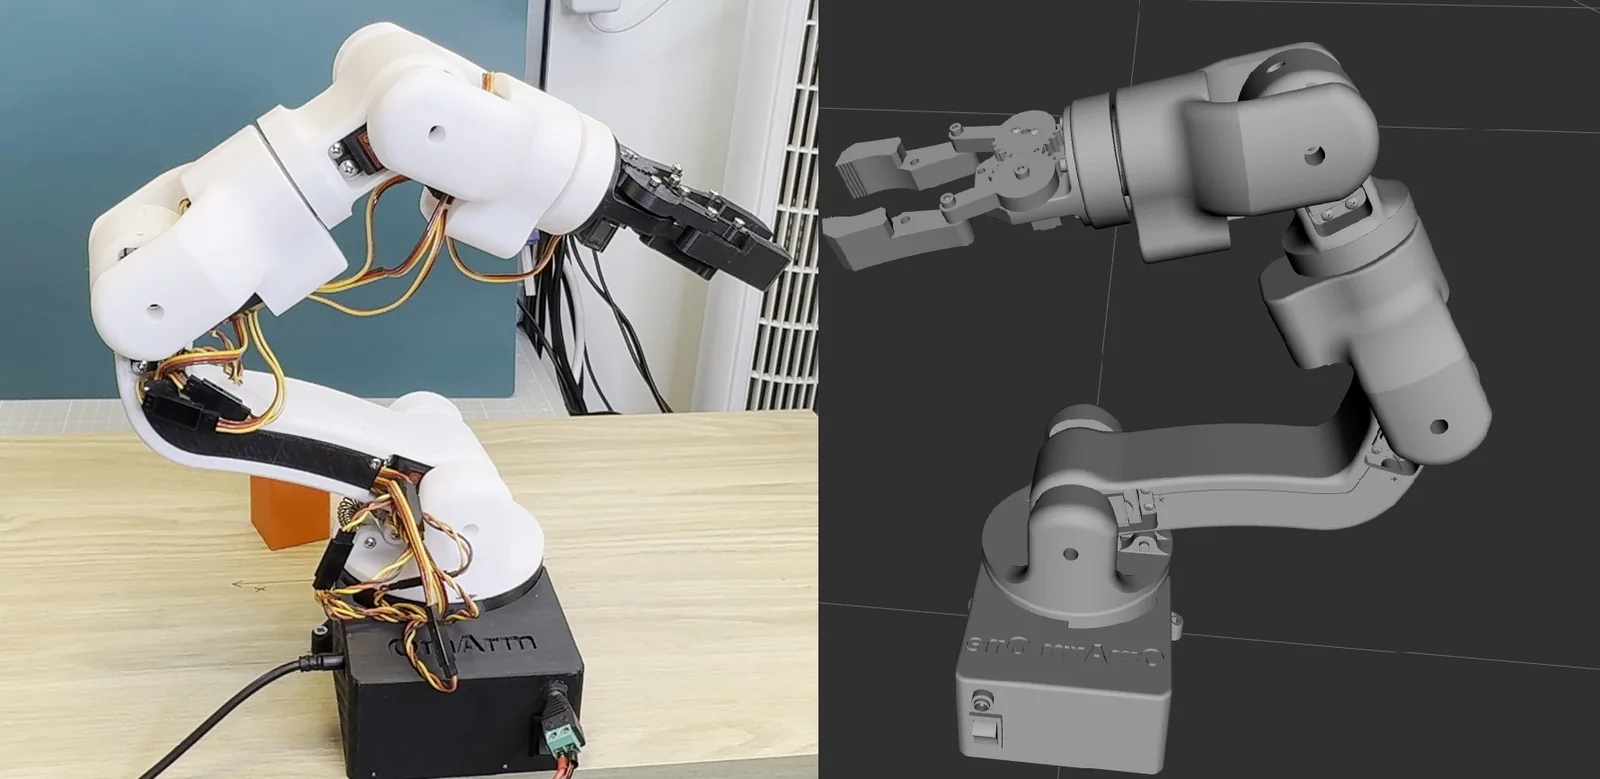
Export a URDF from Fusion 360, audit it, correct joint directions, zeros and limits so the model matches the real OmArm One, and run it in RViz and Gazebo Harmonic. Part 2 of the OmArm One series, for ROS 2 Jazzy.