From Fusion 360 to a ROS 2 Digital Twin: URDF, RViz and Gazebo That Match the Real Arm (OmArm One Part 2)
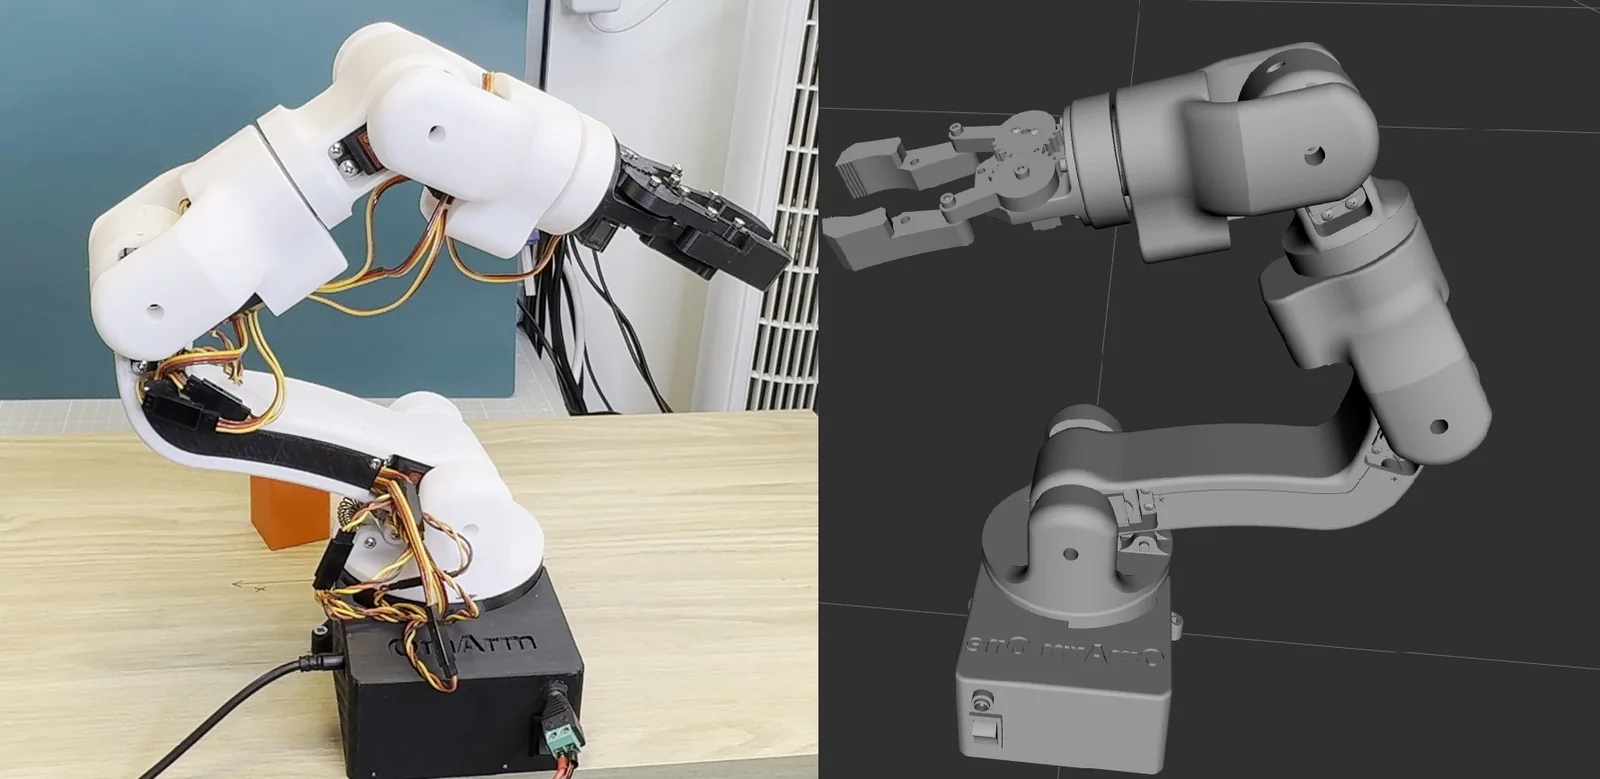
The real 3D printed OmArm One robot arm on a workbench beside the same arm rendered in RViz, both in the same pose

Export a URDF from Fusion 360, audit it, correct joint directions, zeros and limits so the model matches the real OmArm One, and run it in RViz and Gazebo Harmonic. Part 2 of the OmArm One series, with the free ROS 2 Jazzy package.
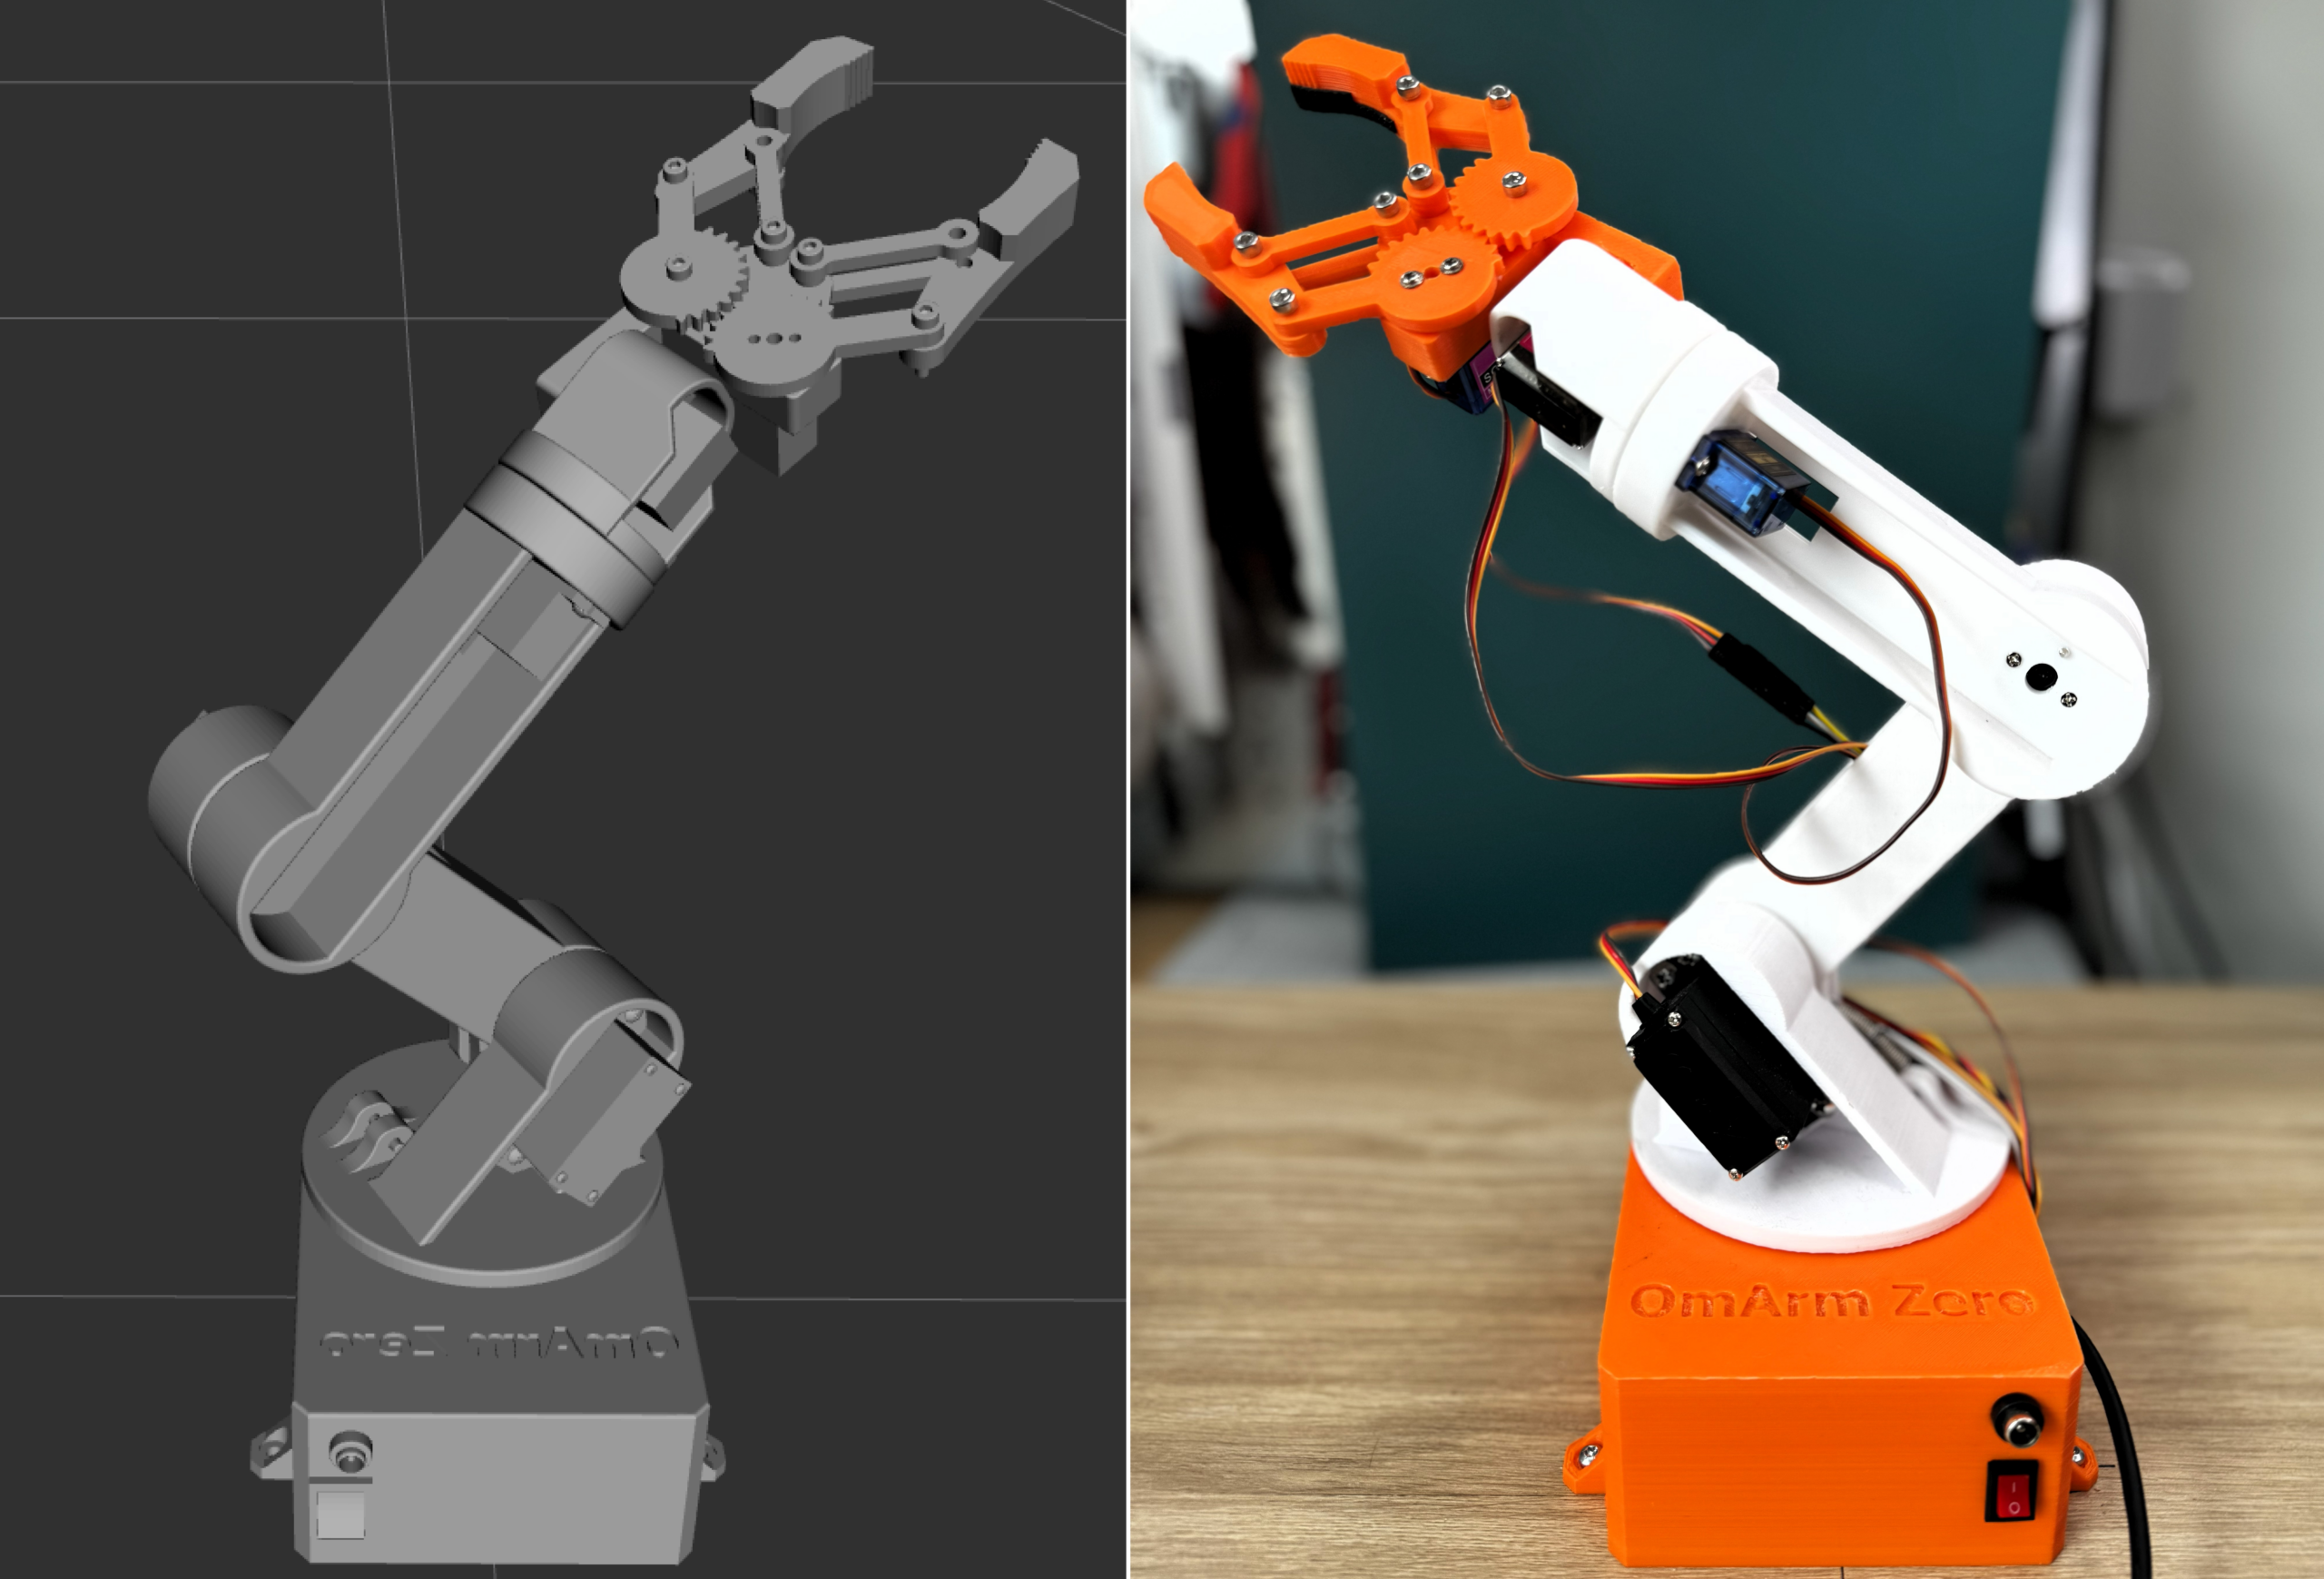
ROS 2 URDF Tutorial: Visualize and Simulate a Robot Arm in RViz and Gazebo

▶The video loads from YouTube (Google), which may set cookies. Privacy policy At a glance What you’ll build: A complete digital twin of a 6-DOF robot arm (the OmArm Zero) using URDF/Xacro, RViz, and Gazebo Harmonic. You’ll go from an empty workspace to a simulated arm that responds to joint trajectory commands with full physics. … Read more