MoveIt 2 on a Real Robot Arm: ros2_control, Inverse Kinematics and a URDF That Matches the Hardware (OmArm One Part 3)
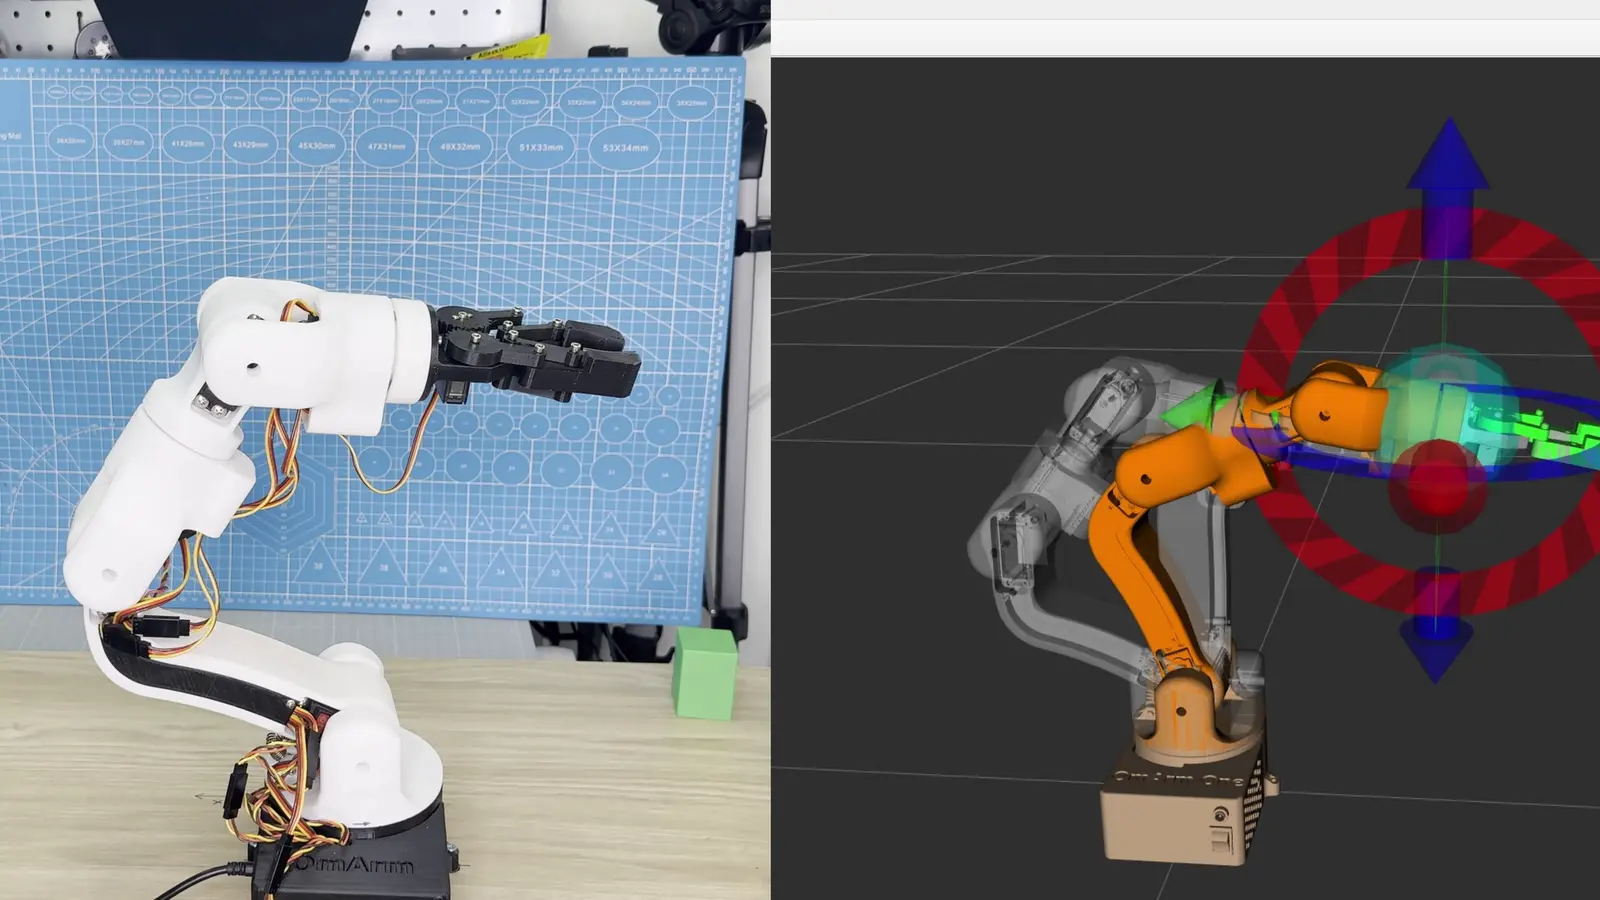
The real OmArm One and its RViz model in the same pose, with the interactive marker on the gripper

MoveIt 2 on a real robot arm with ROS 2 Jazzy: audit the CAD export against the built arm, set up ros2_control, derive the inverse kinematics, build the MoveIt package with the Setup Assistant and drive an ESP32 arm over one USB cable.
MoveIt 2 Tutorial: Motion Planning and Real Robot Control for a 6-DOF Arm

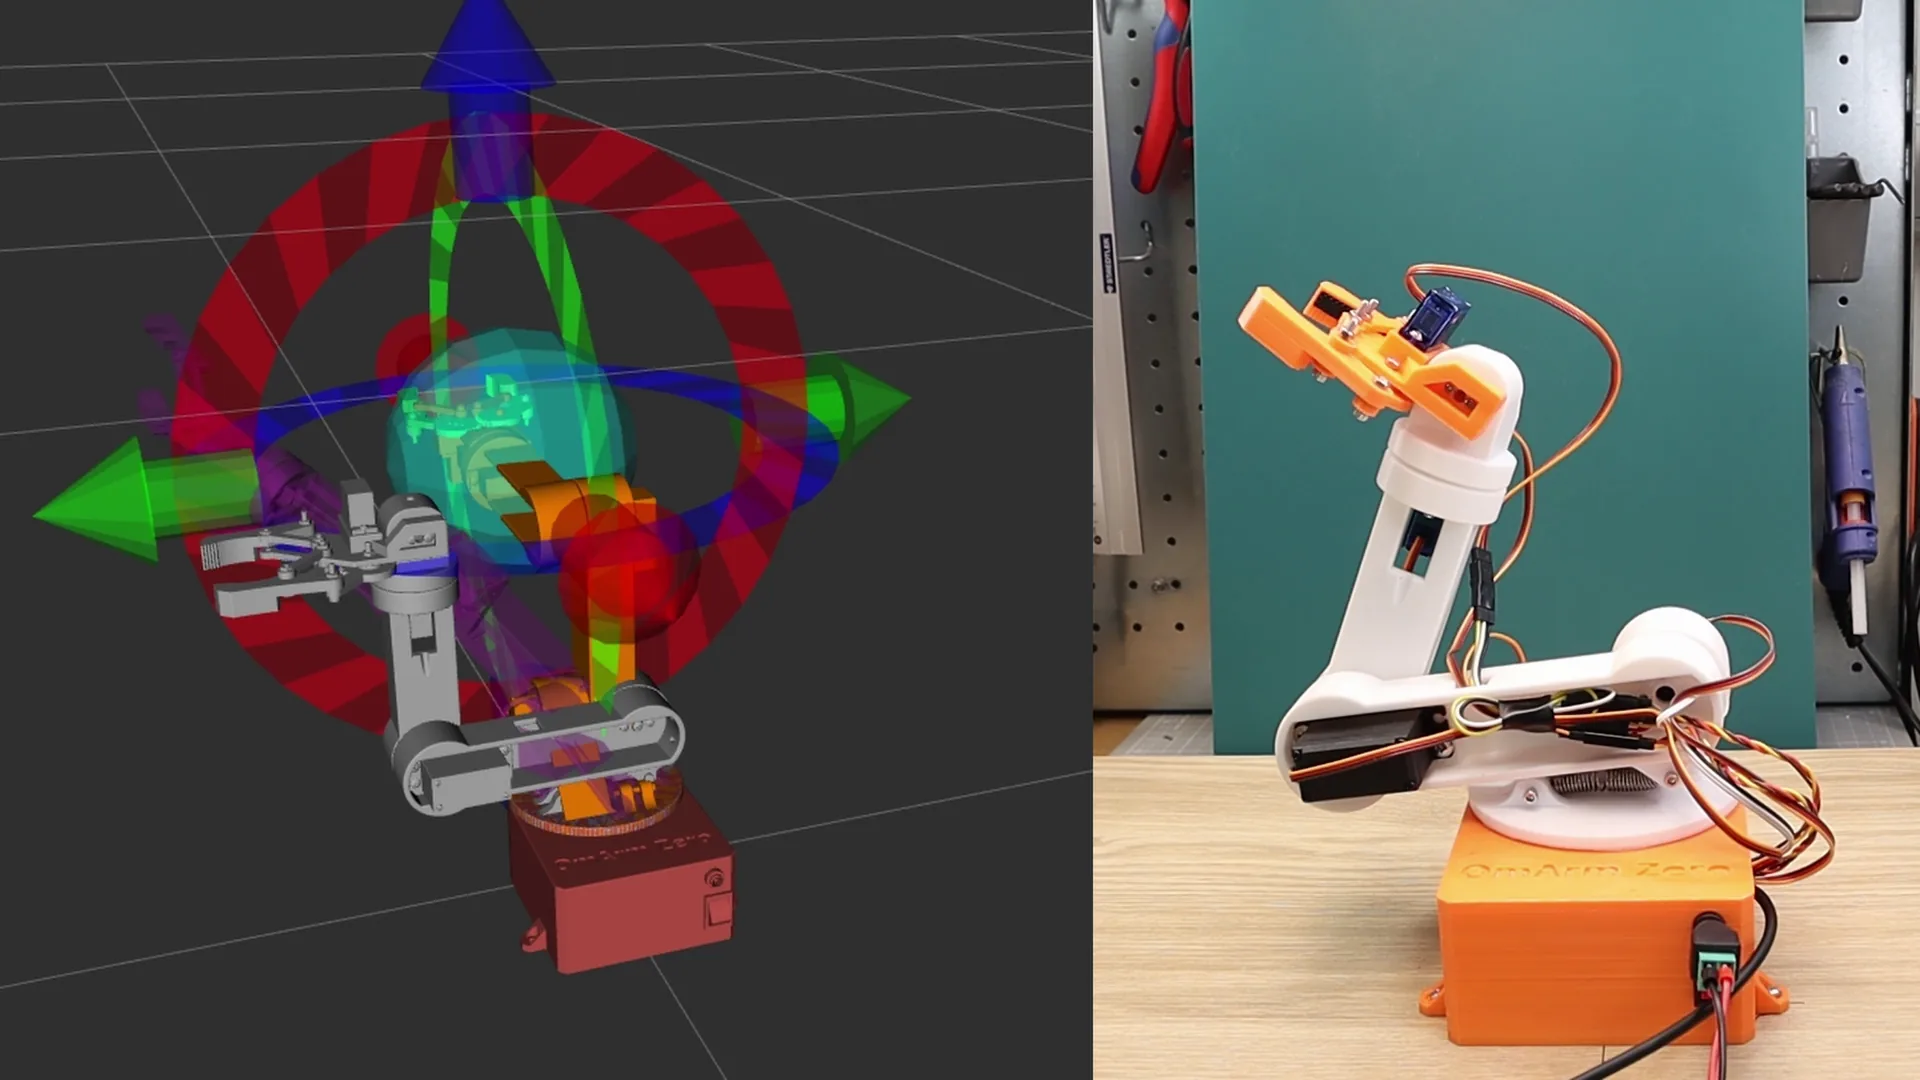
OmArm Zero robot arm with MoveIt 2 motion planning visualization in RViz

Part 3 of the OmArm Zero series: set up MoveIt 2 for the 6-DOF (5+1 gripper) arm, plan collision-free motions in RViz and execute them on the real ESP32 arm over a serial bridge.