MoveIt 2 on a Real Robot Arm: ros2_control, Inverse Kinematics and a URDF That Matches the Hardware (OmArm One Part 3)
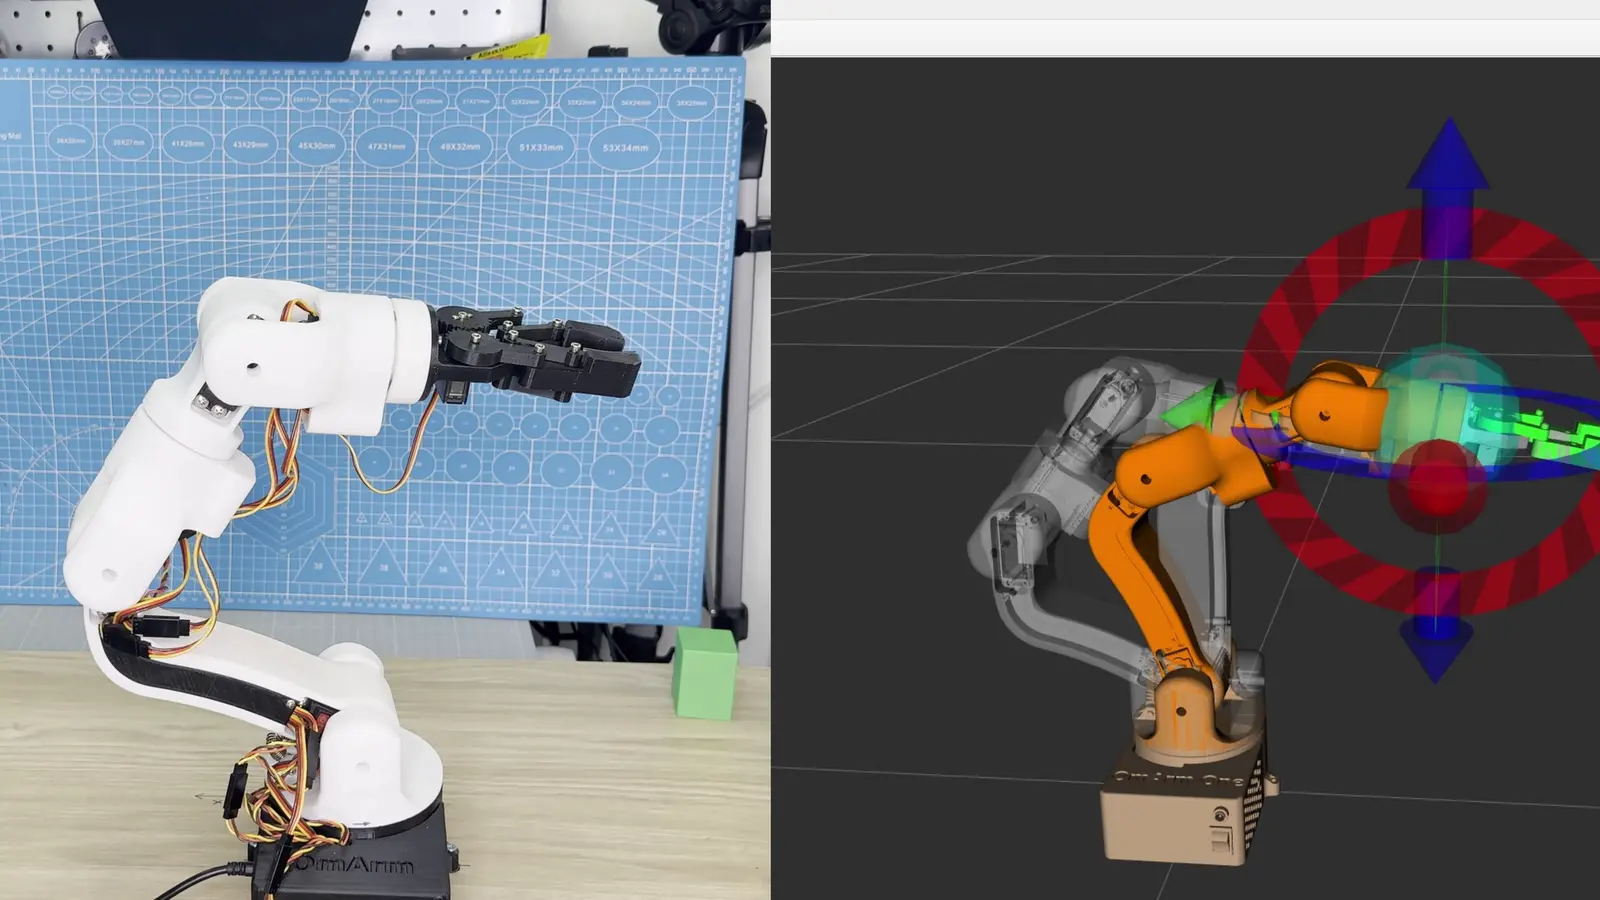
The real OmArm One and its RViz model in the same pose, with the interactive marker on the gripper

MoveIt 2 on a real robot arm with ROS 2 Jazzy: audit the CAD export against the built arm, set up ros2_control, derive the inverse kinematics, build the MoveIt package with the Setup Assistant and drive an ESP32 arm over one USB cable.
شرح MoveIt 2: تخطيط الحركة والتحكم في الروبوت الحقيقي لذراع بست درجات حرية (6-DOF)

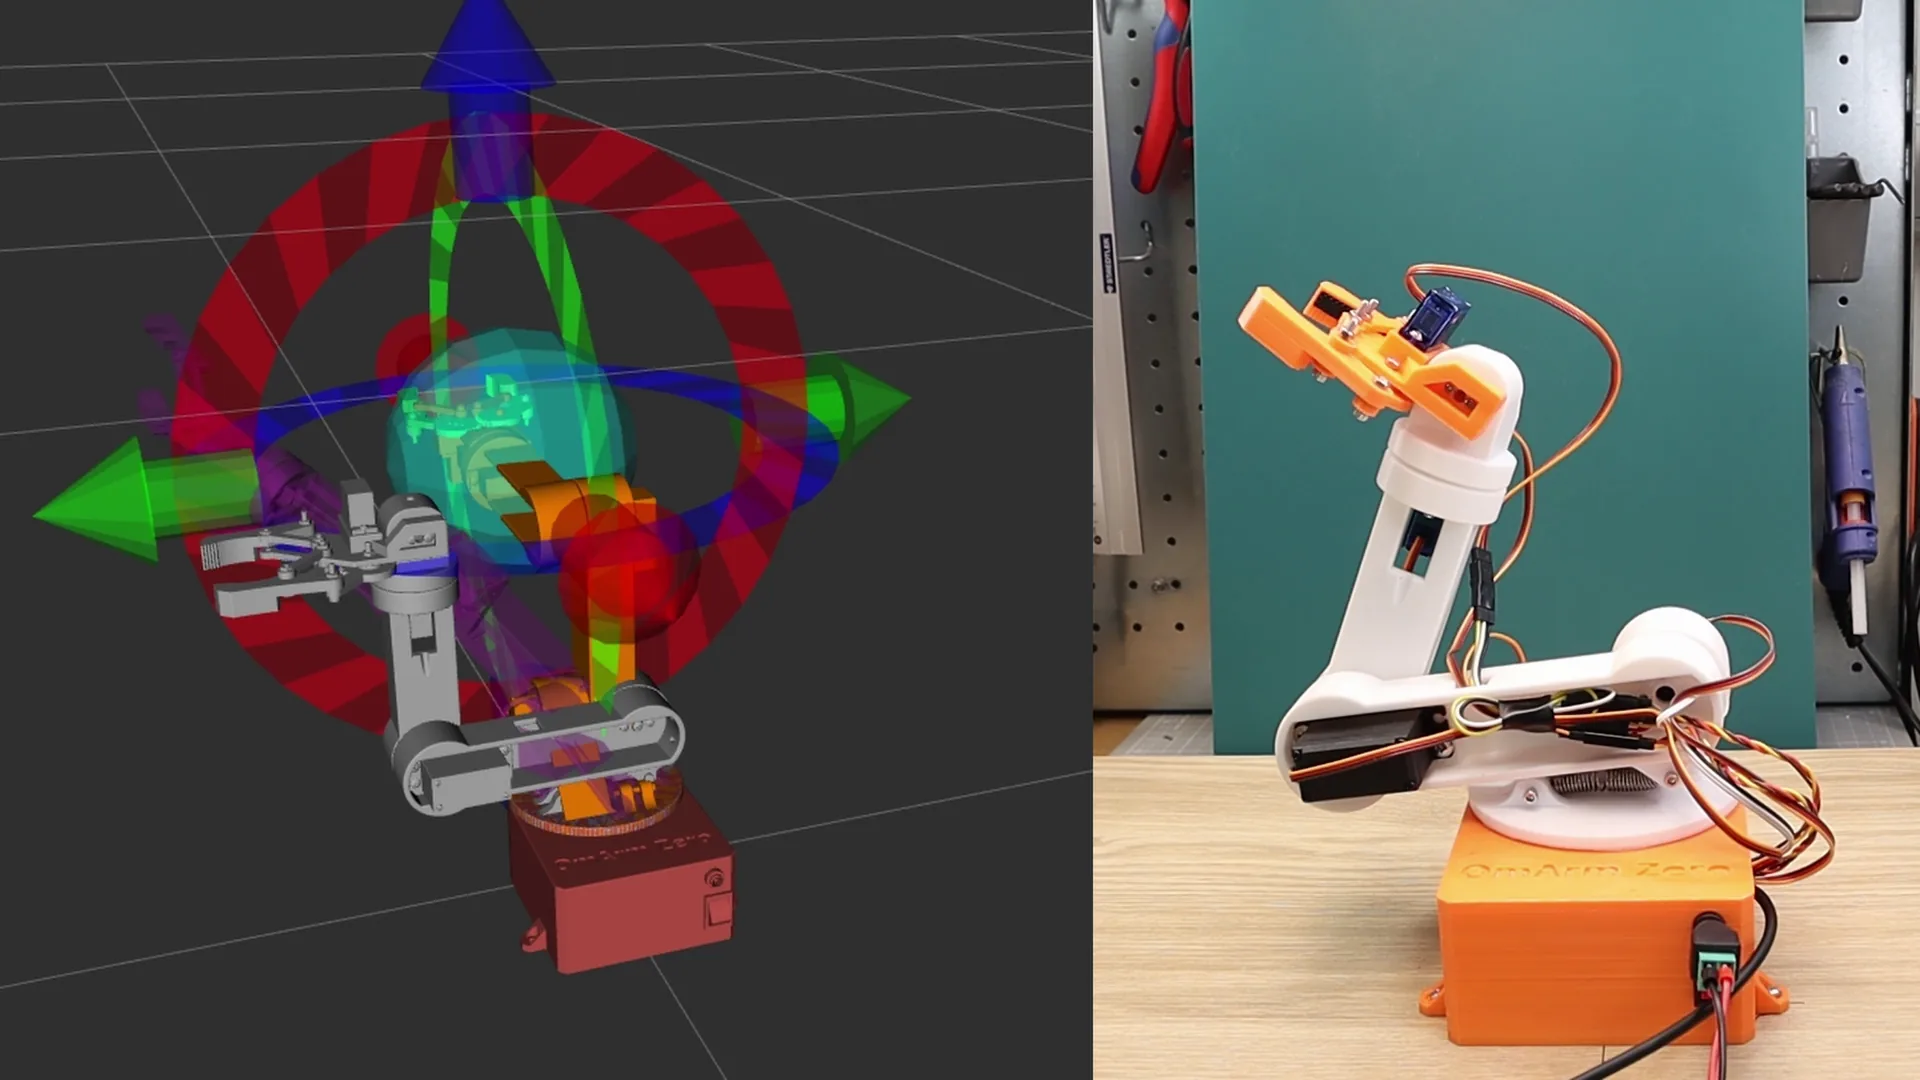
OmArm Zero robot arm with MoveIt 2 motion planning visualization in RViz

الجزء 3 من سلسلة OmArm Zero: اضبط MoveIt 2 للذراع بست درجات حرية (6-DOF، أي 5+1 للقابض)، وخطّط حركات خالية من التصادم في RViz، ونفّذها على ذراع ESP32 الحقيقية عبر جسر تسلسلي (Serial Bridge).