MoveIt 2 on a Real Robot Arm: ros2_control, Inverse Kinematics and a URDF That Matches the Hardware (OmArm One Part 3)
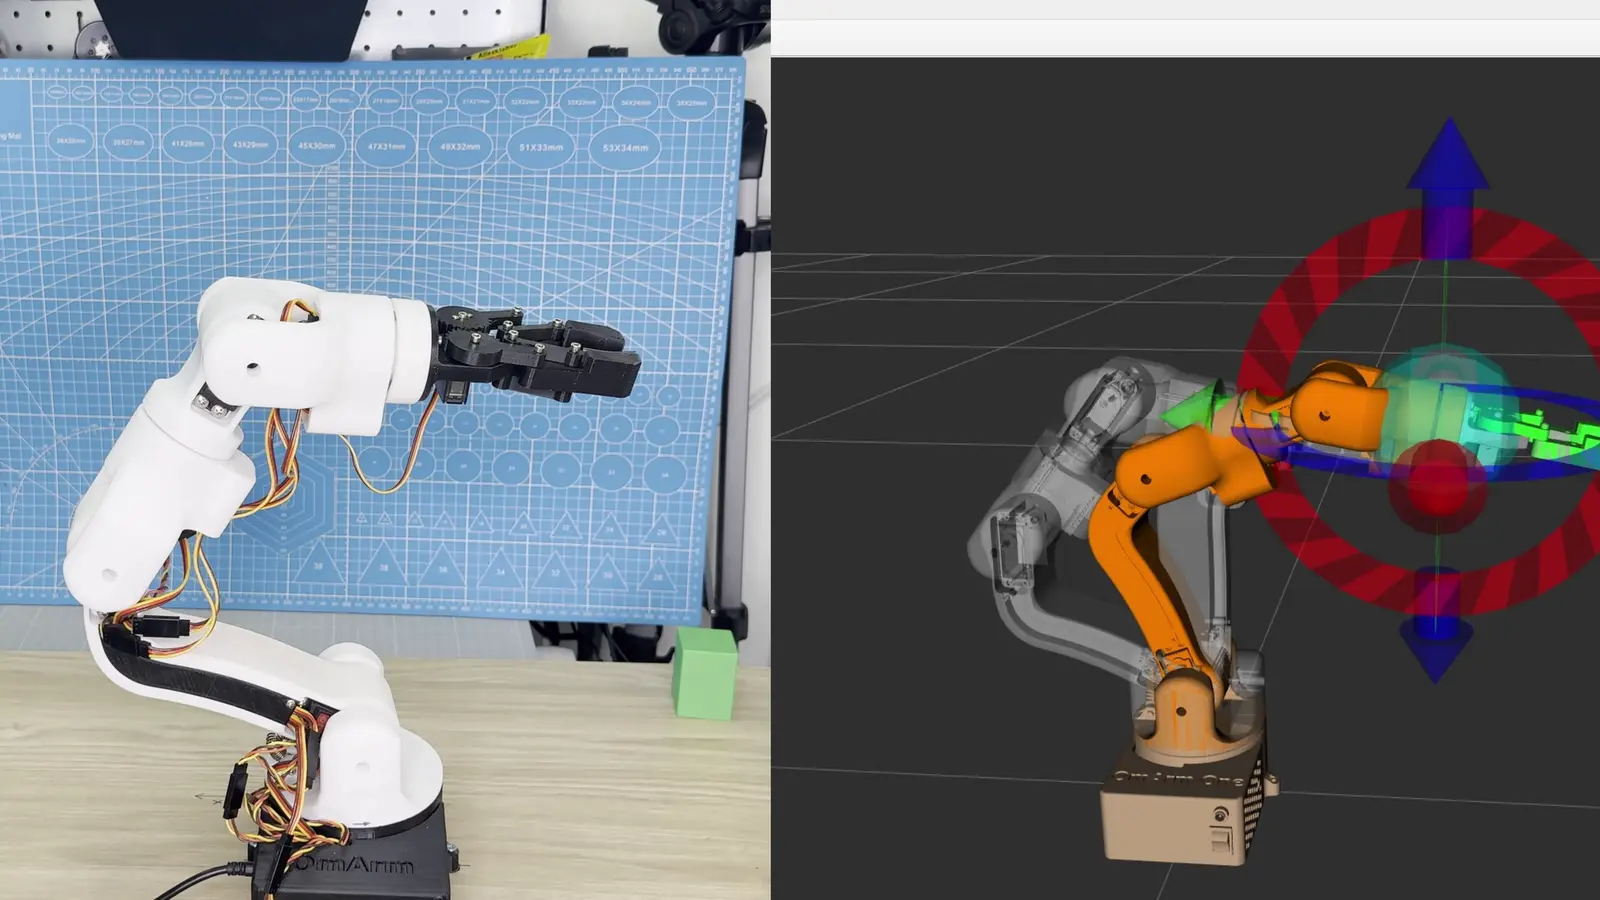
The real OmArm One and its RViz model in the same pose, with the interactive marker on the gripper

MoveIt 2 on a real robot arm with ROS 2 Jazzy: audit the CAD export against the built arm, set up ros2_control, derive the inverse kinematics, build the MoveIt package with the Setup Assistant and drive an ESP32 arm over one USB cable.
من Fusion 360 إلى توأم رقمي في ROS 2: نموذج URDF وRViz وGazebo مطابقة للذراع الحقيقية (OmArm One، الجزء 2)

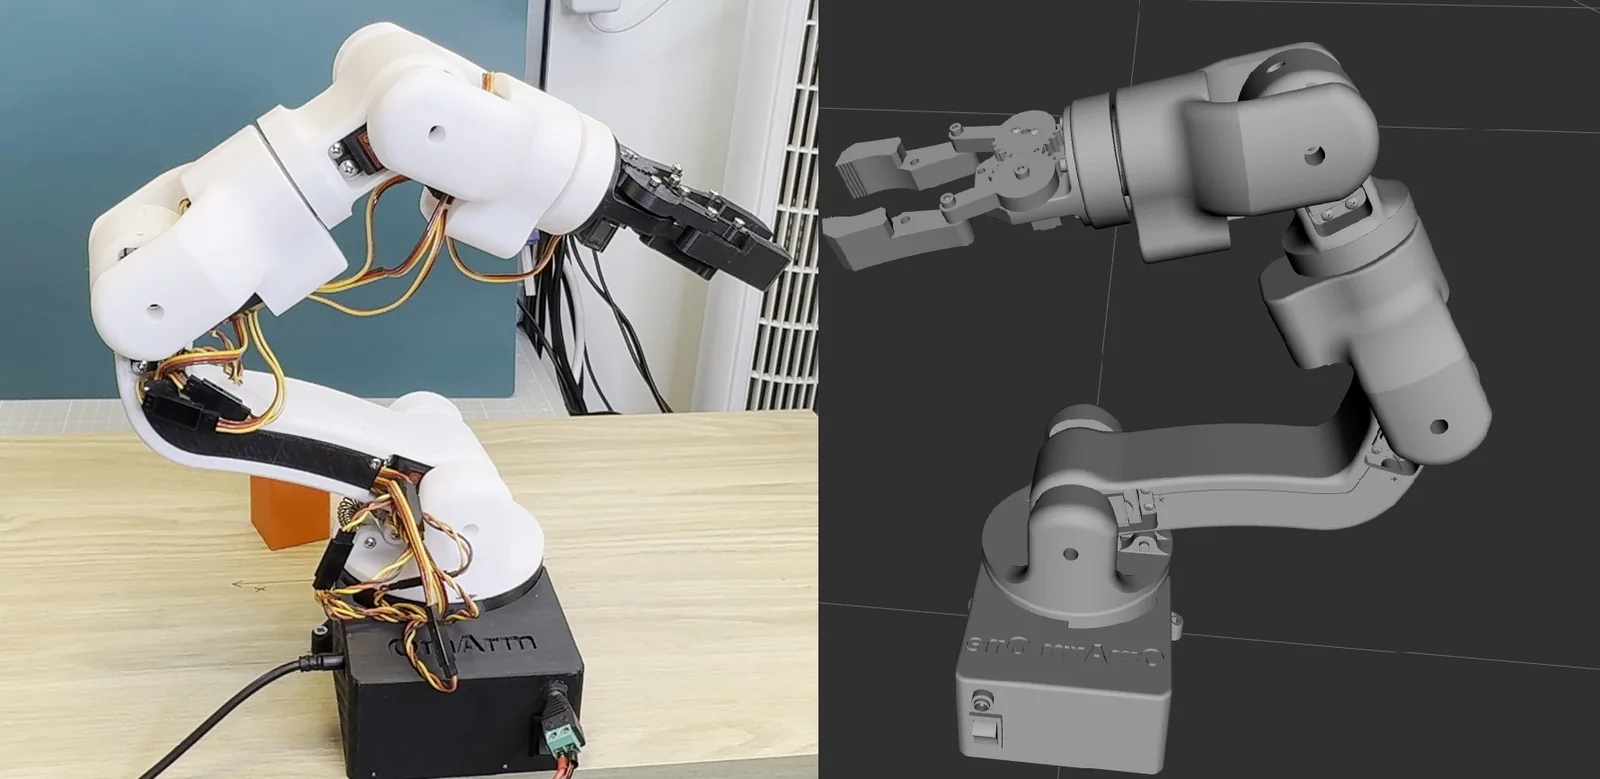
The real 3D printed OmArm One robot arm on a workbench beside the same arm rendered in RViz, both in the same pose

صدّر ملف URDF من Fusion 360، وراجعه، وصحّح اتجاهات المفاصل ونقاط الصفر والحدود حتى يطابق النموذج ذراع OmArm One الحقيقية، ثم شغّله في RViz وGazebo Harmonic. الجزء 2 من سلسلة OmArm One، لـ ROS 2 Jazzy.