MoveIt 2 on a Real Robot Arm: ros2_control, Inverse Kinematics and a URDF That Matches the Hardware (OmArm One Part 3)
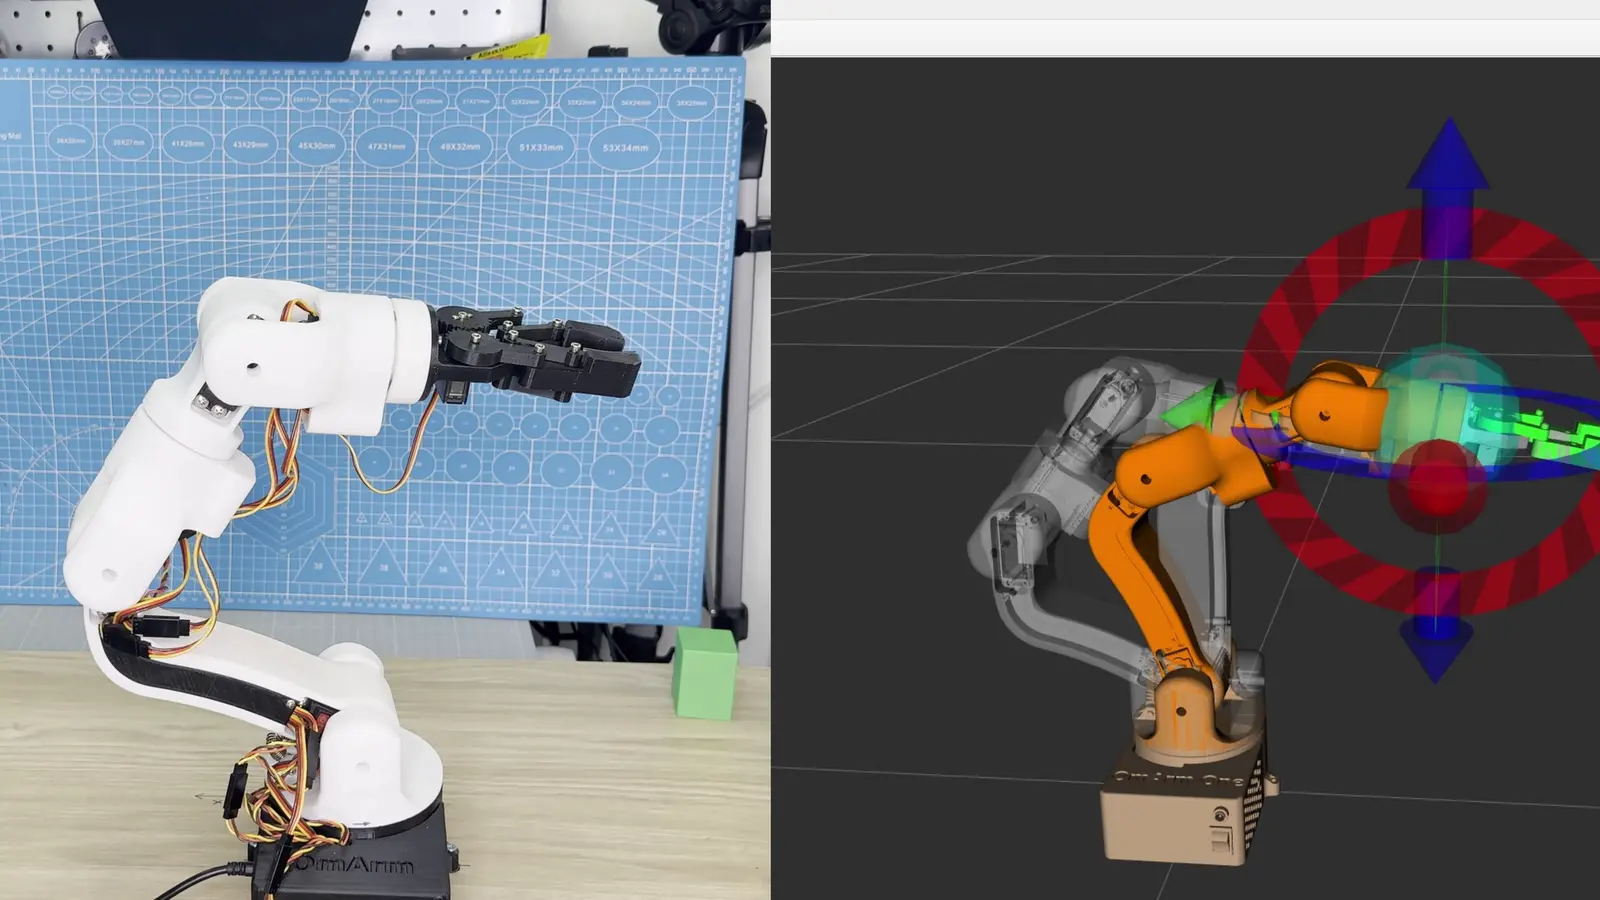
The real OmArm One and its RViz model in the same pose, with the interactive marker on the gripper

MoveIt 2 on a real robot arm with ROS 2 Jazzy: audit the CAD export against the built arm, set up ros2_control, derive the inverse kinematics, build the MoveIt package with the Setup Assistant and drive an ESP32 arm over one USB cable.
قيادة ذراع روبوتية مطبوعة بتقنية ثلاثية الأبعاد (3D) بوحدة تحكم PS3: ESP32 وبلوتوث ودون حاسوب (OmArm One، الجزء 1.5)

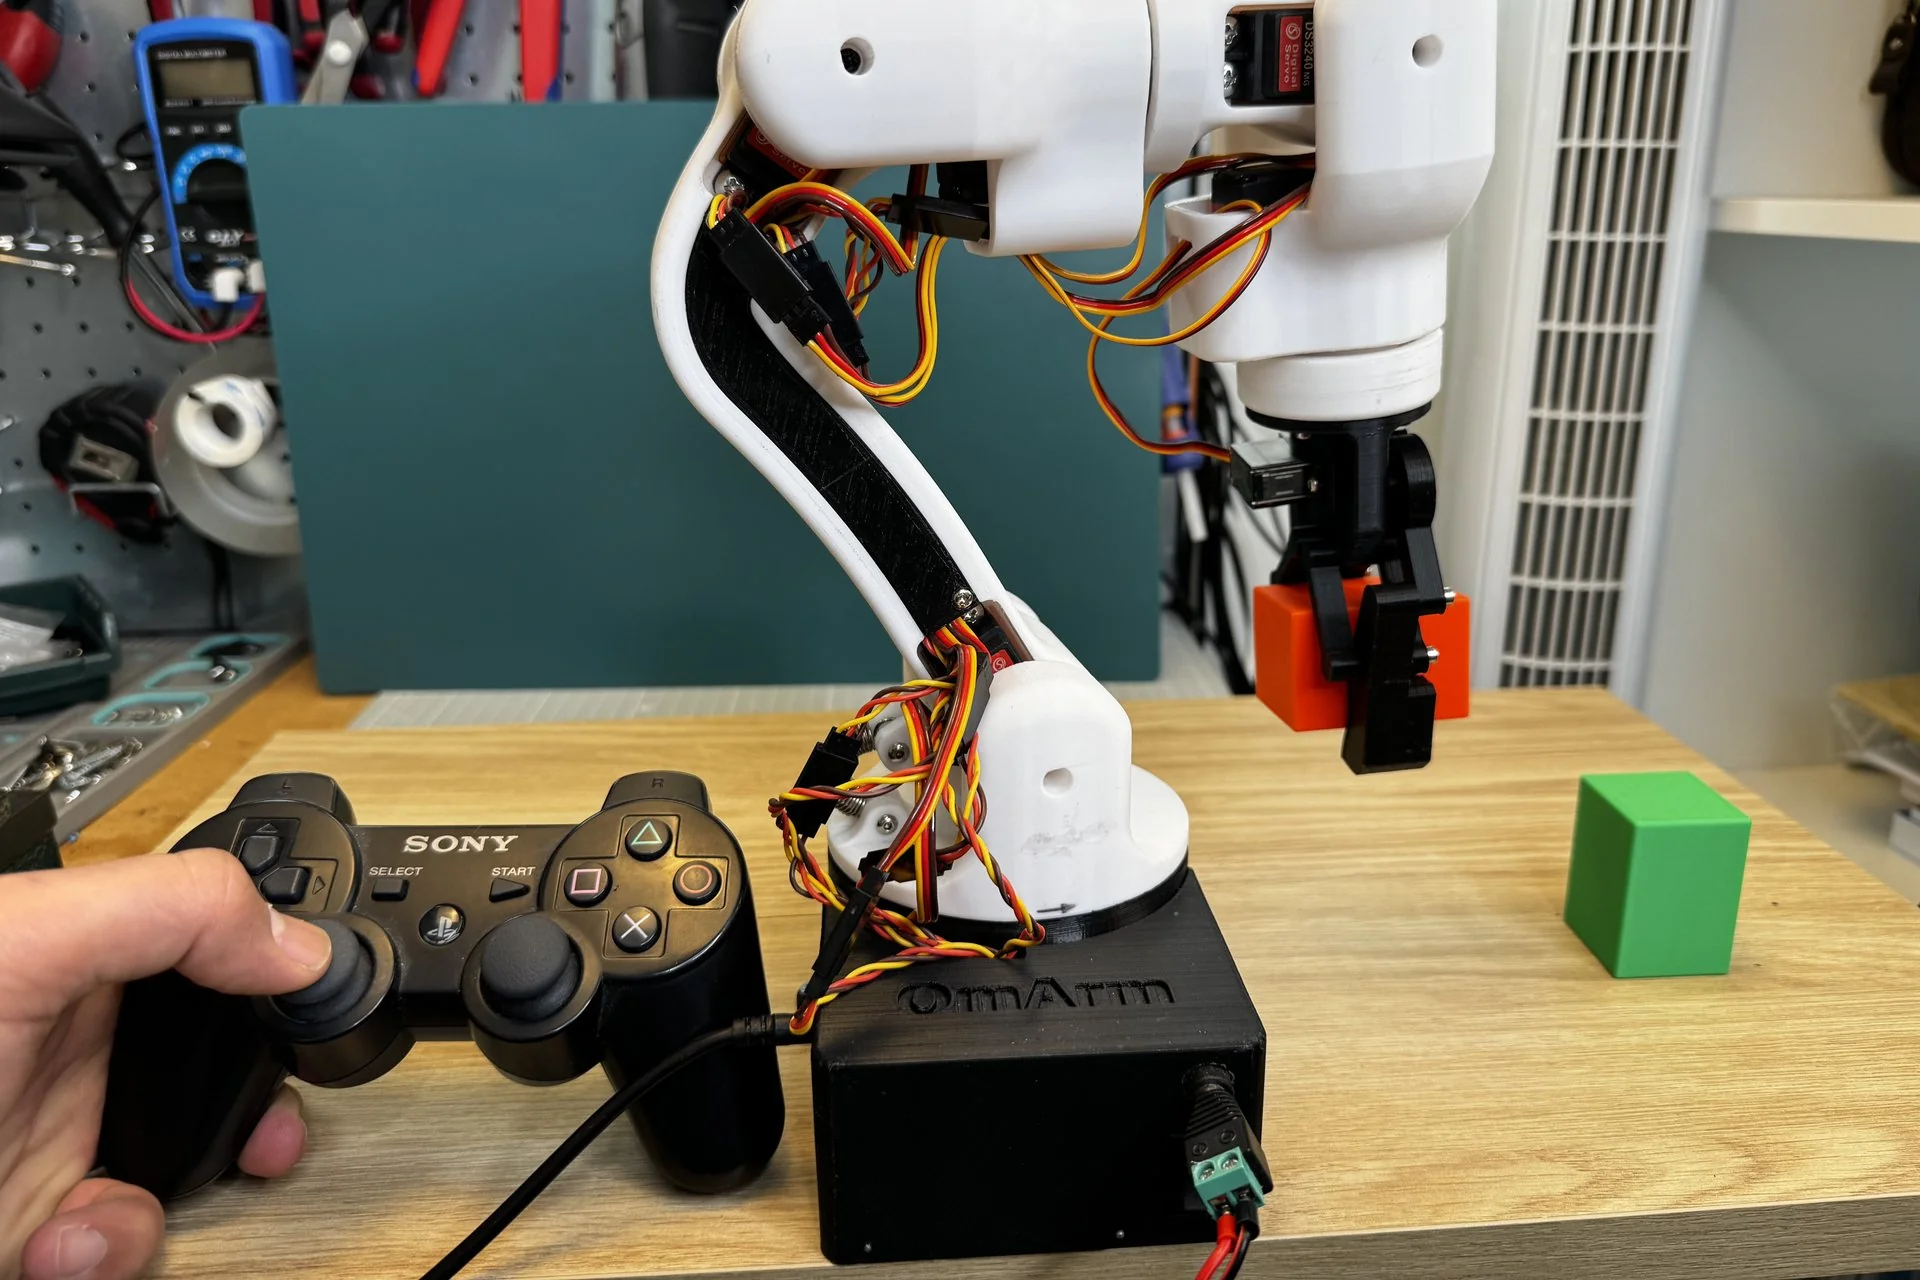
A DualShock 3 controller held in one hand with the 3D printed OmArm One robot arm behind it holding an orange cube

اربط يد تحكم PS3 بـESP32 عبر Bluepad32 وحرّك ذراعًا روبوتية مطبوعة بالطباعة ثلاثية الأبعاد (3D) بسبع درجات حرية (7-DOF، أي 6+1 للقابض): عصوان للتحكم بالسرعة، وأربعة مستويات للسرعة، وتسلسل وضعيات مسجَّل، وإيقاف يبقى مثبتًا، دون الحاجة إلى أي حاسوب.

OmArm One: بناء ذراع روبوتية بسبع درجات حرية (7-DOF) بالطباعة ثلاثية الأبعاد (3D) على محامل كروية حقيقية (الجزء 1)

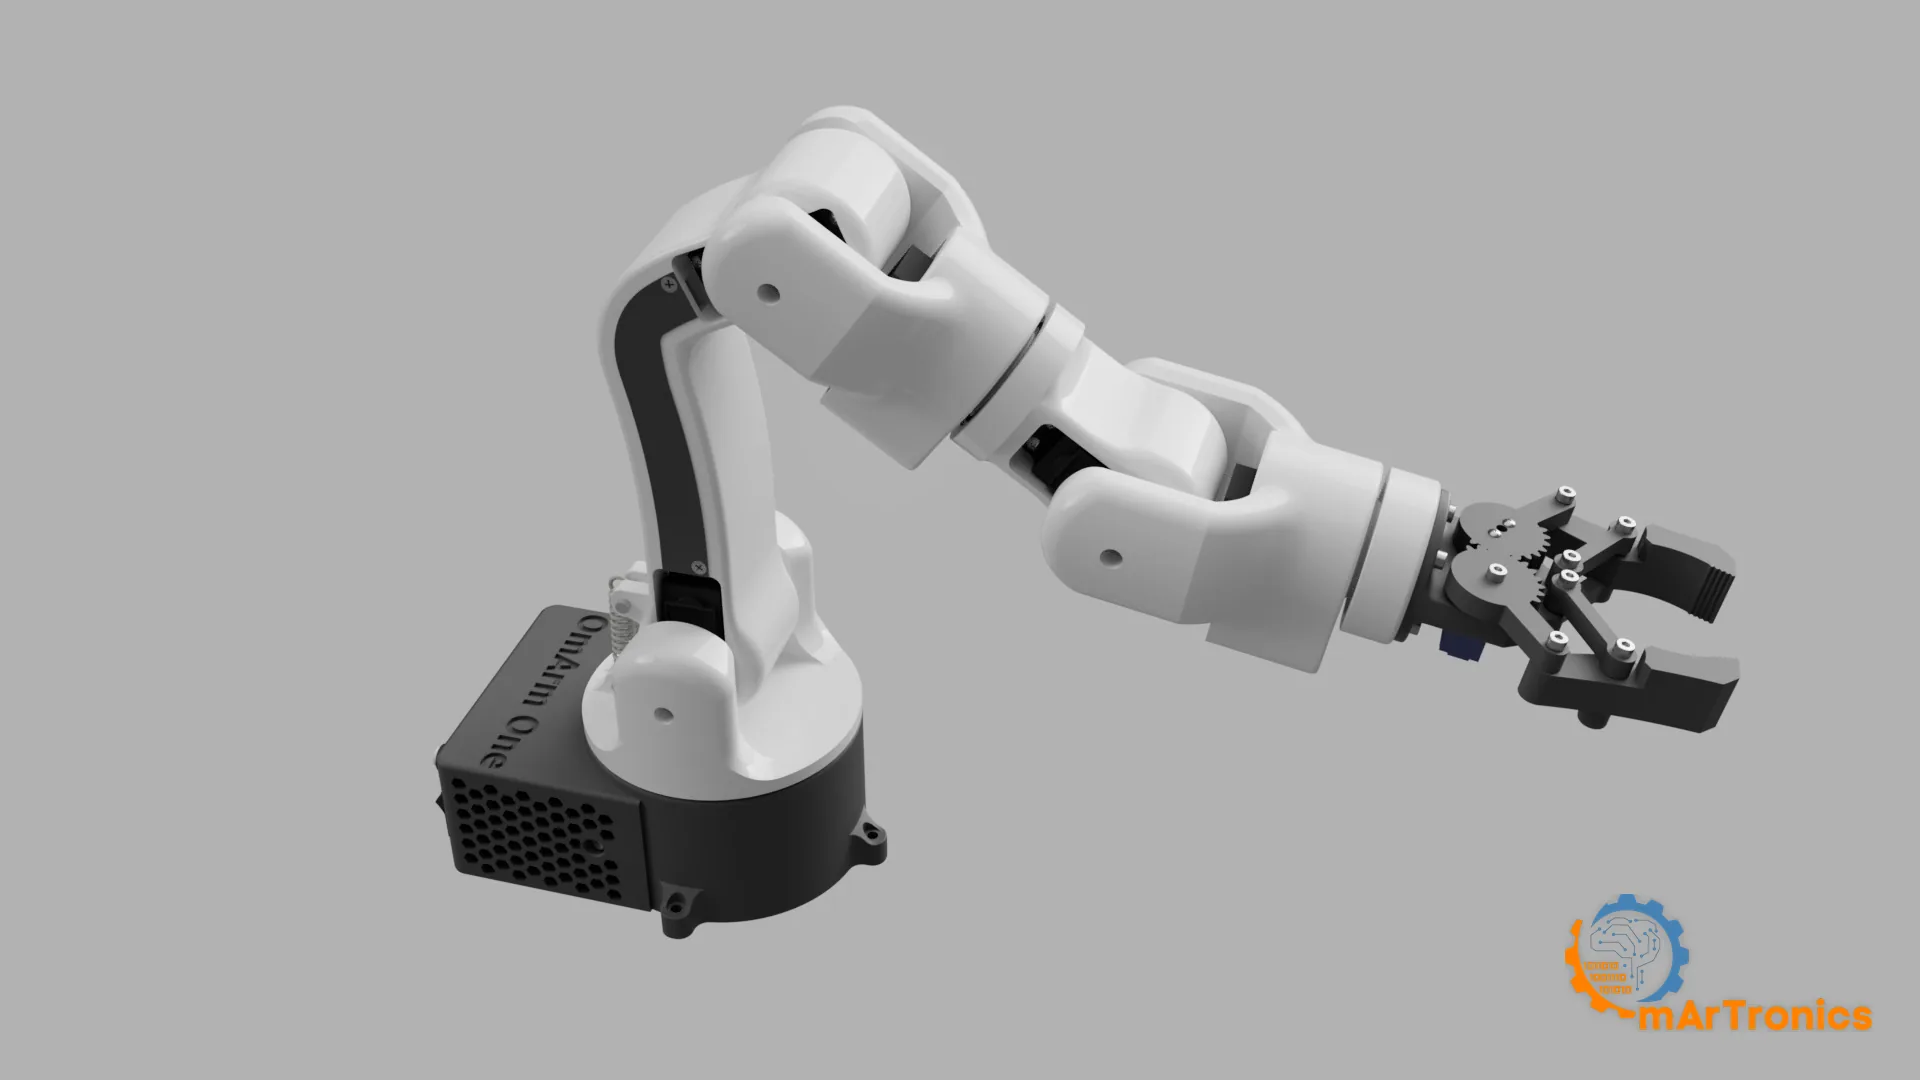
OmArm One, a 6-joint printed arm with a parallel-jaw gripper, rendered from the CAD assembly

ابنِ ذراعًا روبوتية مطبوعة بطابعة ثلاثية الأبعاد بسبع درجات حرية (7 DOF) تدور على محامل كروية حقيقية: مدى وصول 485 mm، وحمولة 200 g، وقائمة مواد (BOM) كاملة، و16 رسمًا متحركًا للتجميع، وتحكم عبر الويب بلوحة ESP32.