MoveIt 2 on a Real Robot Arm: ros2_control, Inverse Kinematics and a URDF That Matches the Hardware (OmArm One Part 3)
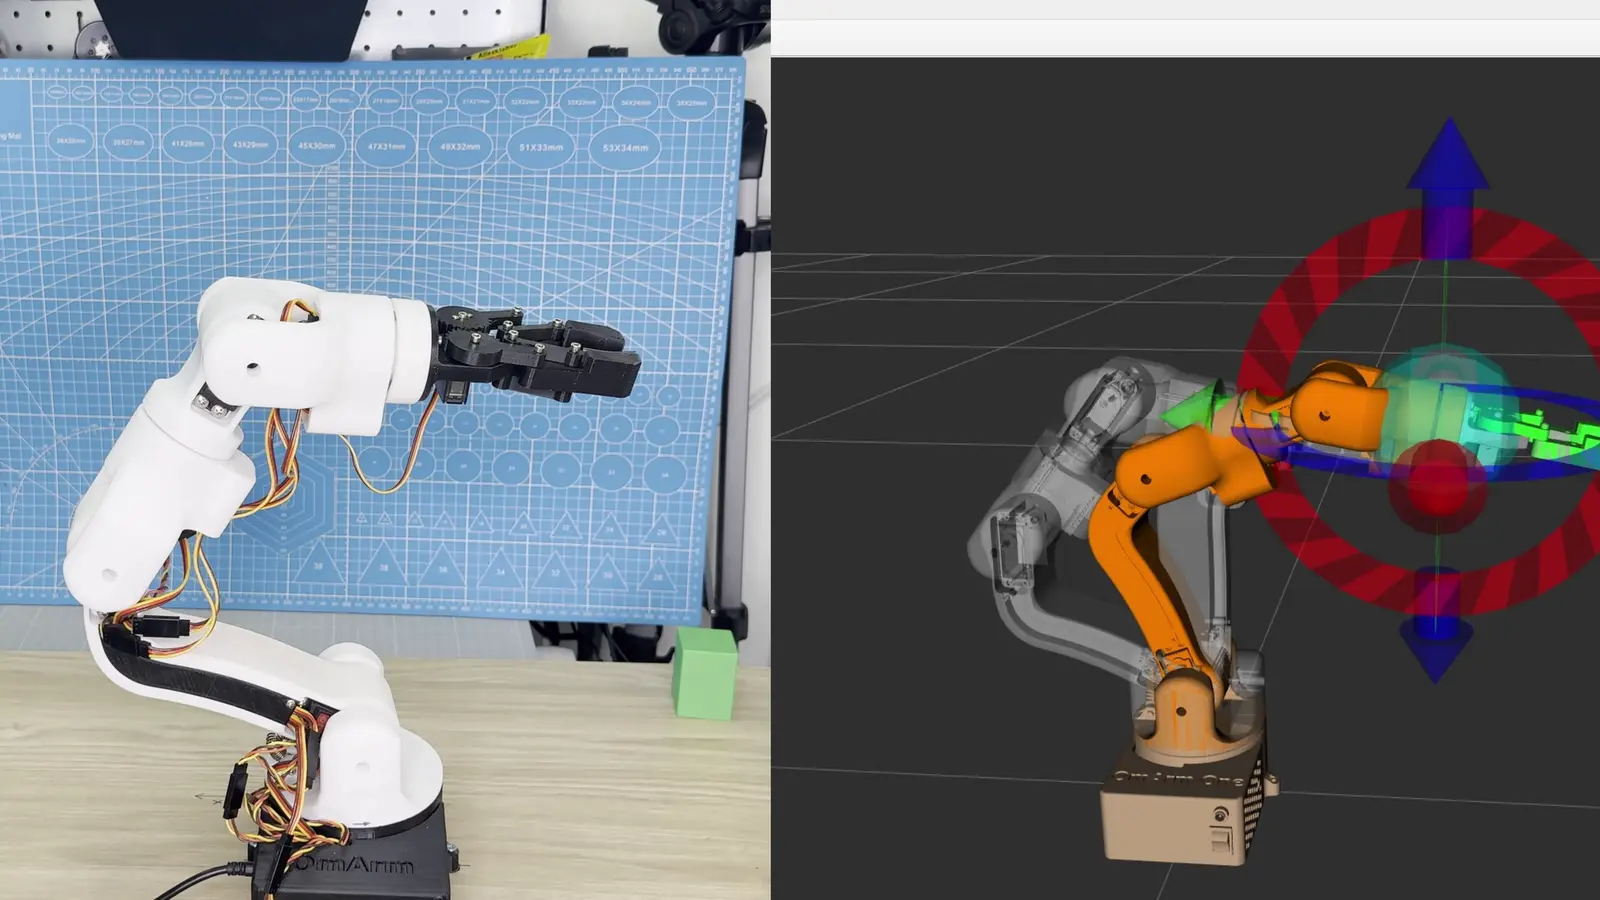
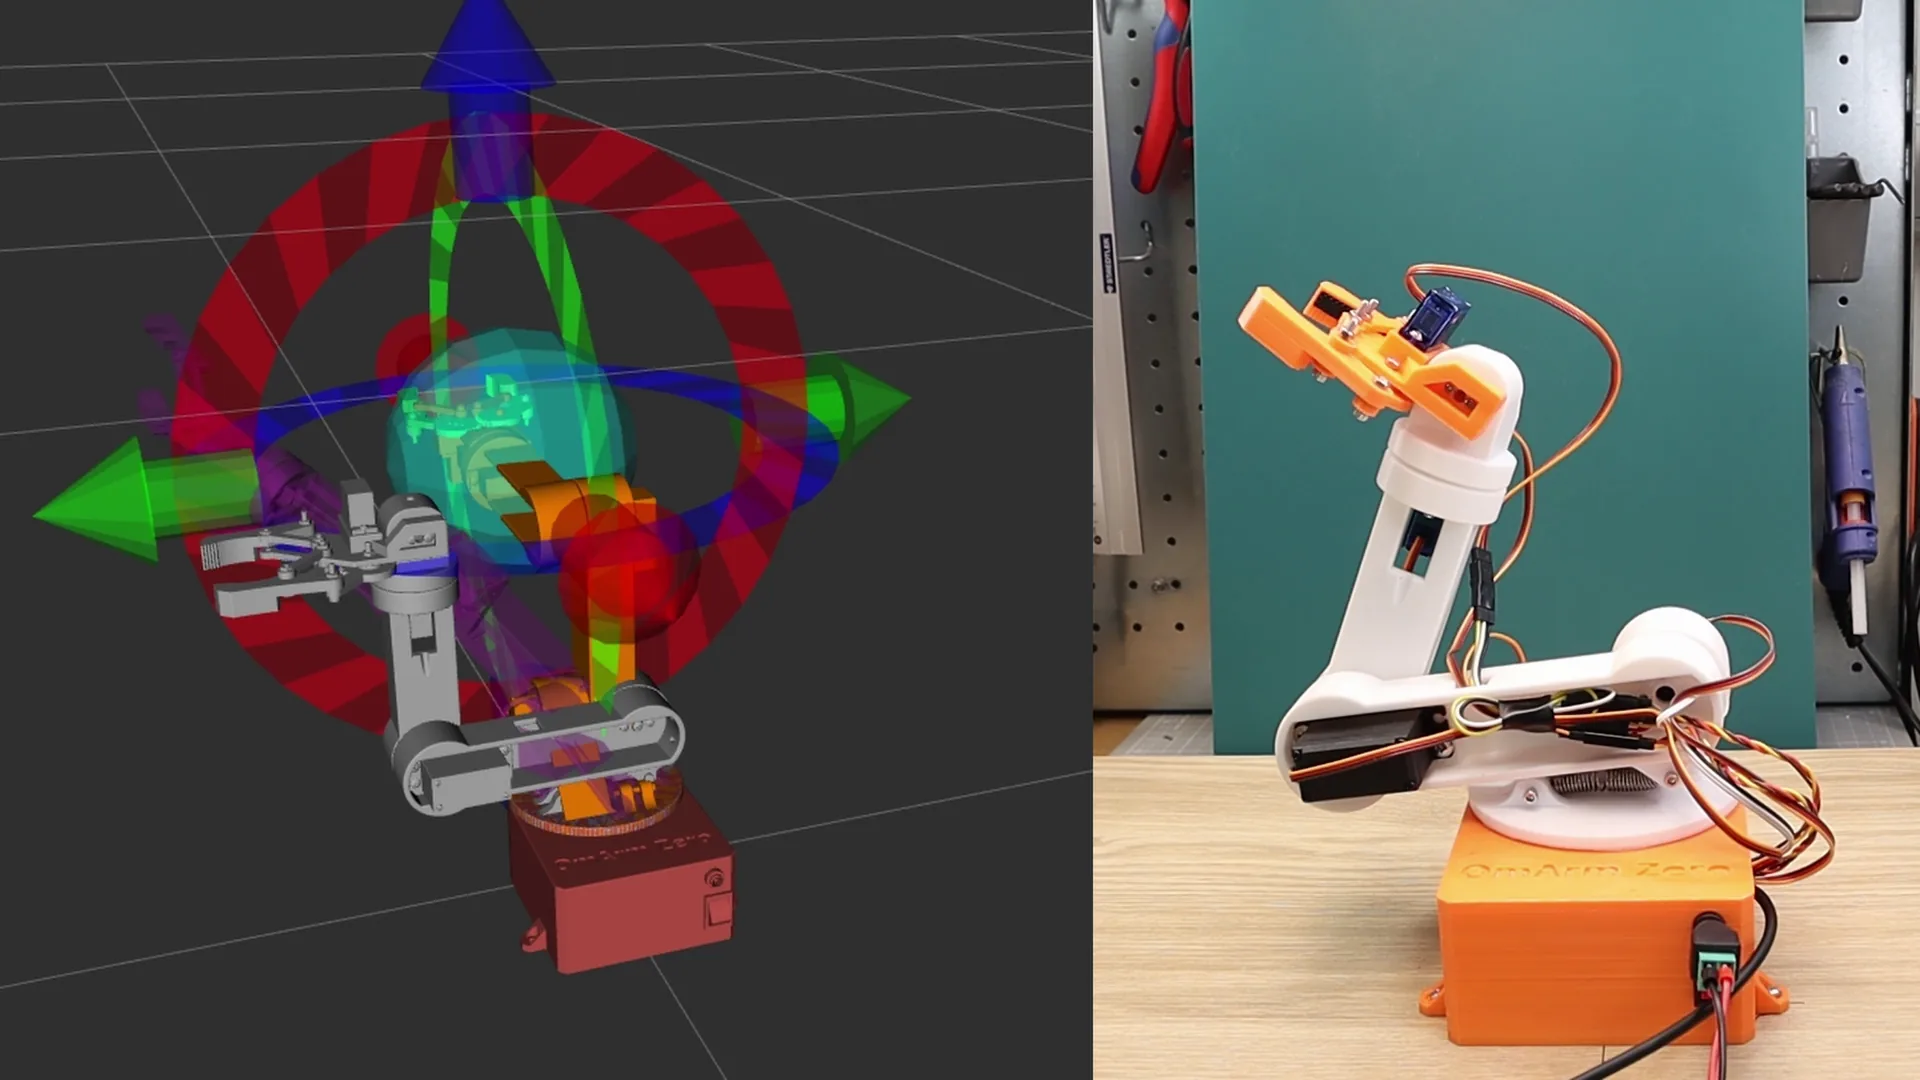
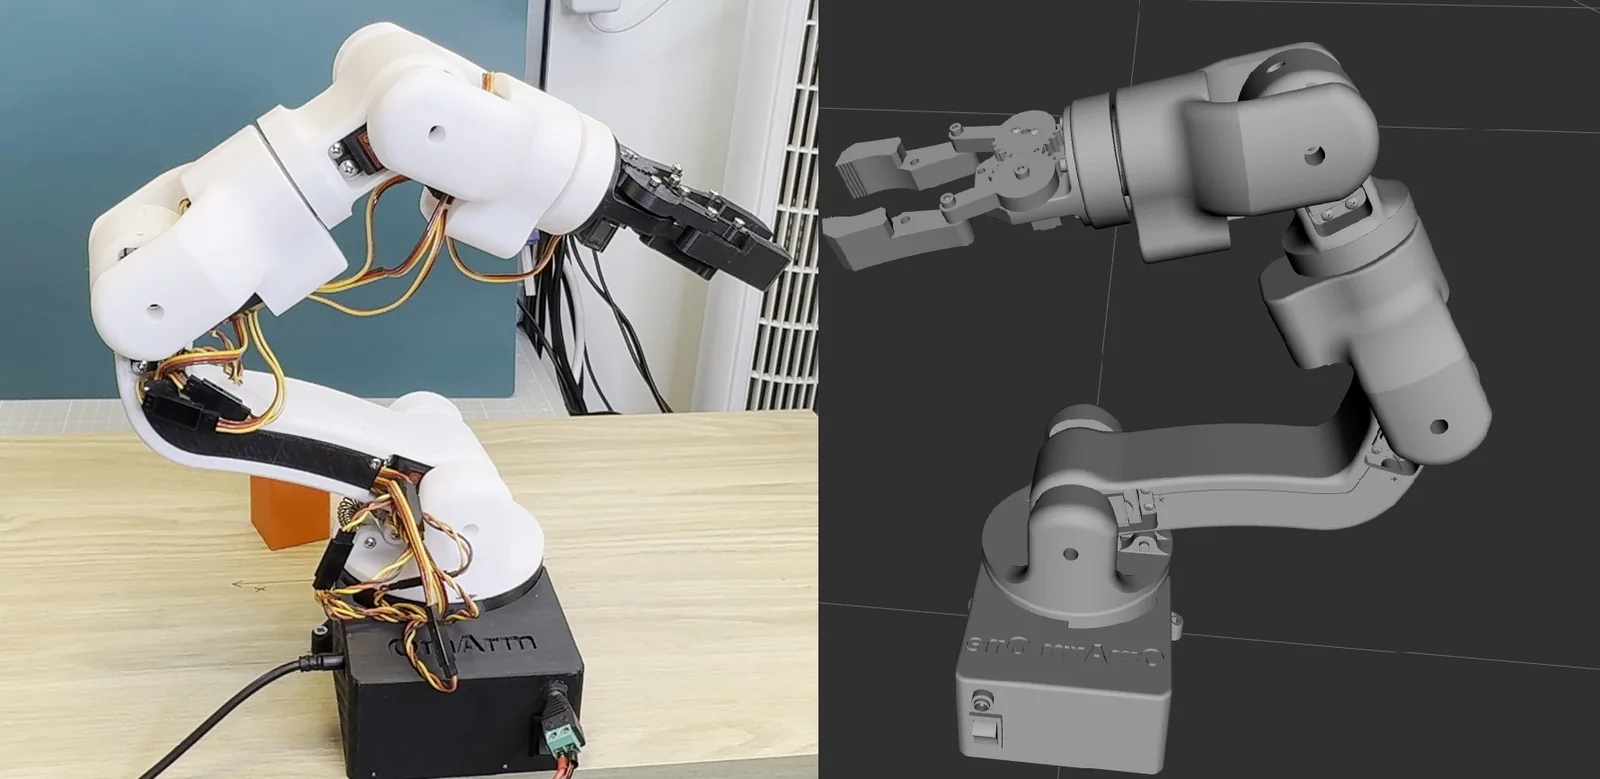
The real OmArm One and its RViz model in the same pose, with the interactive marker on the gripper

MoveIt 2 on a real robot arm with ROS 2 Jazzy: audit the CAD export against the built arm, set up ros2_control, derive the inverse kinematics, build the MoveIt package with the Setup Assistant and drive an ESP32 arm over one USB cable.
كيف تبني ذراعًا روبوتية بست محاور في المنزل: مقارنة بين أربعة تصاميم مفتوحة

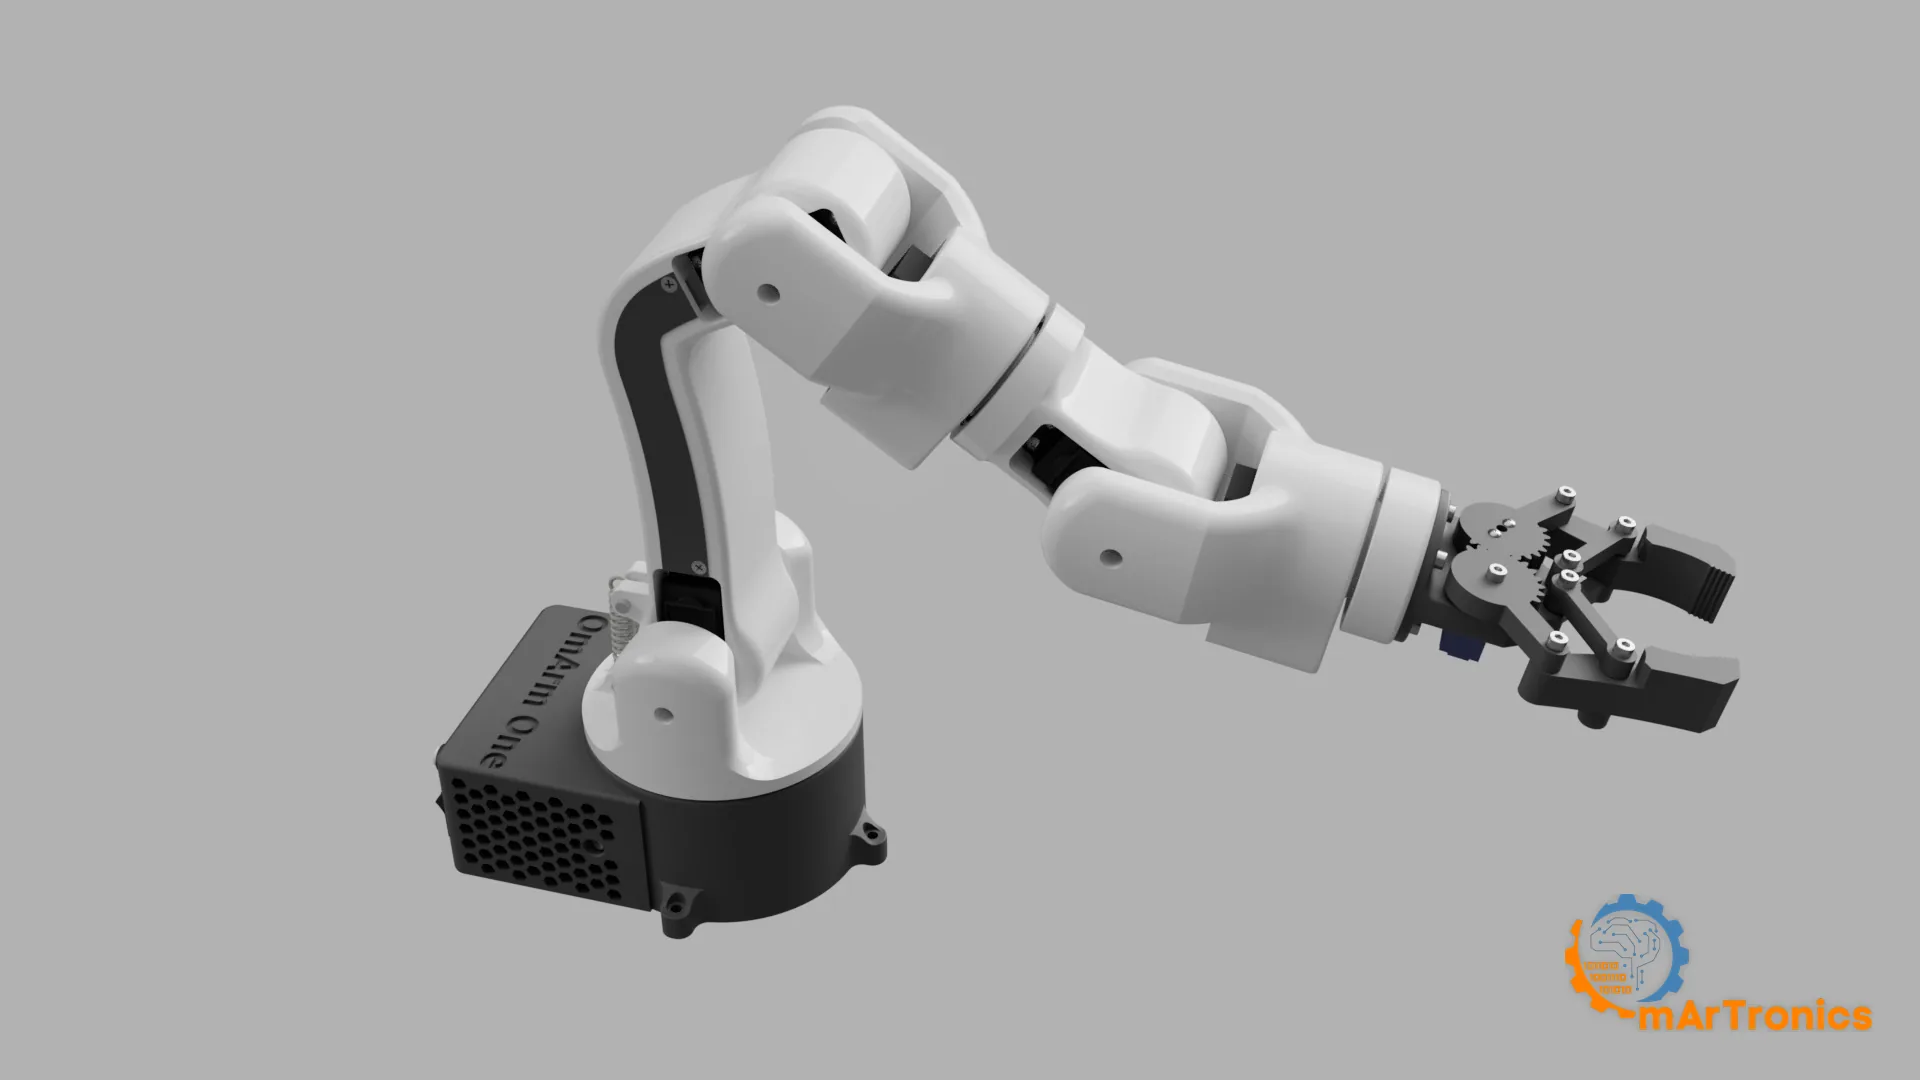
OmArm One, a 6-joint printed arm with a parallel-jaw gripper, rendered from the CAD assembly

Four 3D printed robot arms compared: the Arduino arm, the Bluetooth arm, the OmArm Zero with ESP32 and ROS 2, and the OmArm One on ball bearings. What 6-axis means, which to build first, and where the files are.

من Fusion 360 إلى توأم رقمي في ROS 2: نموذج URDF وRViz وGazebo مطابقة للذراع الحقيقية (OmArm One، الجزء 2)

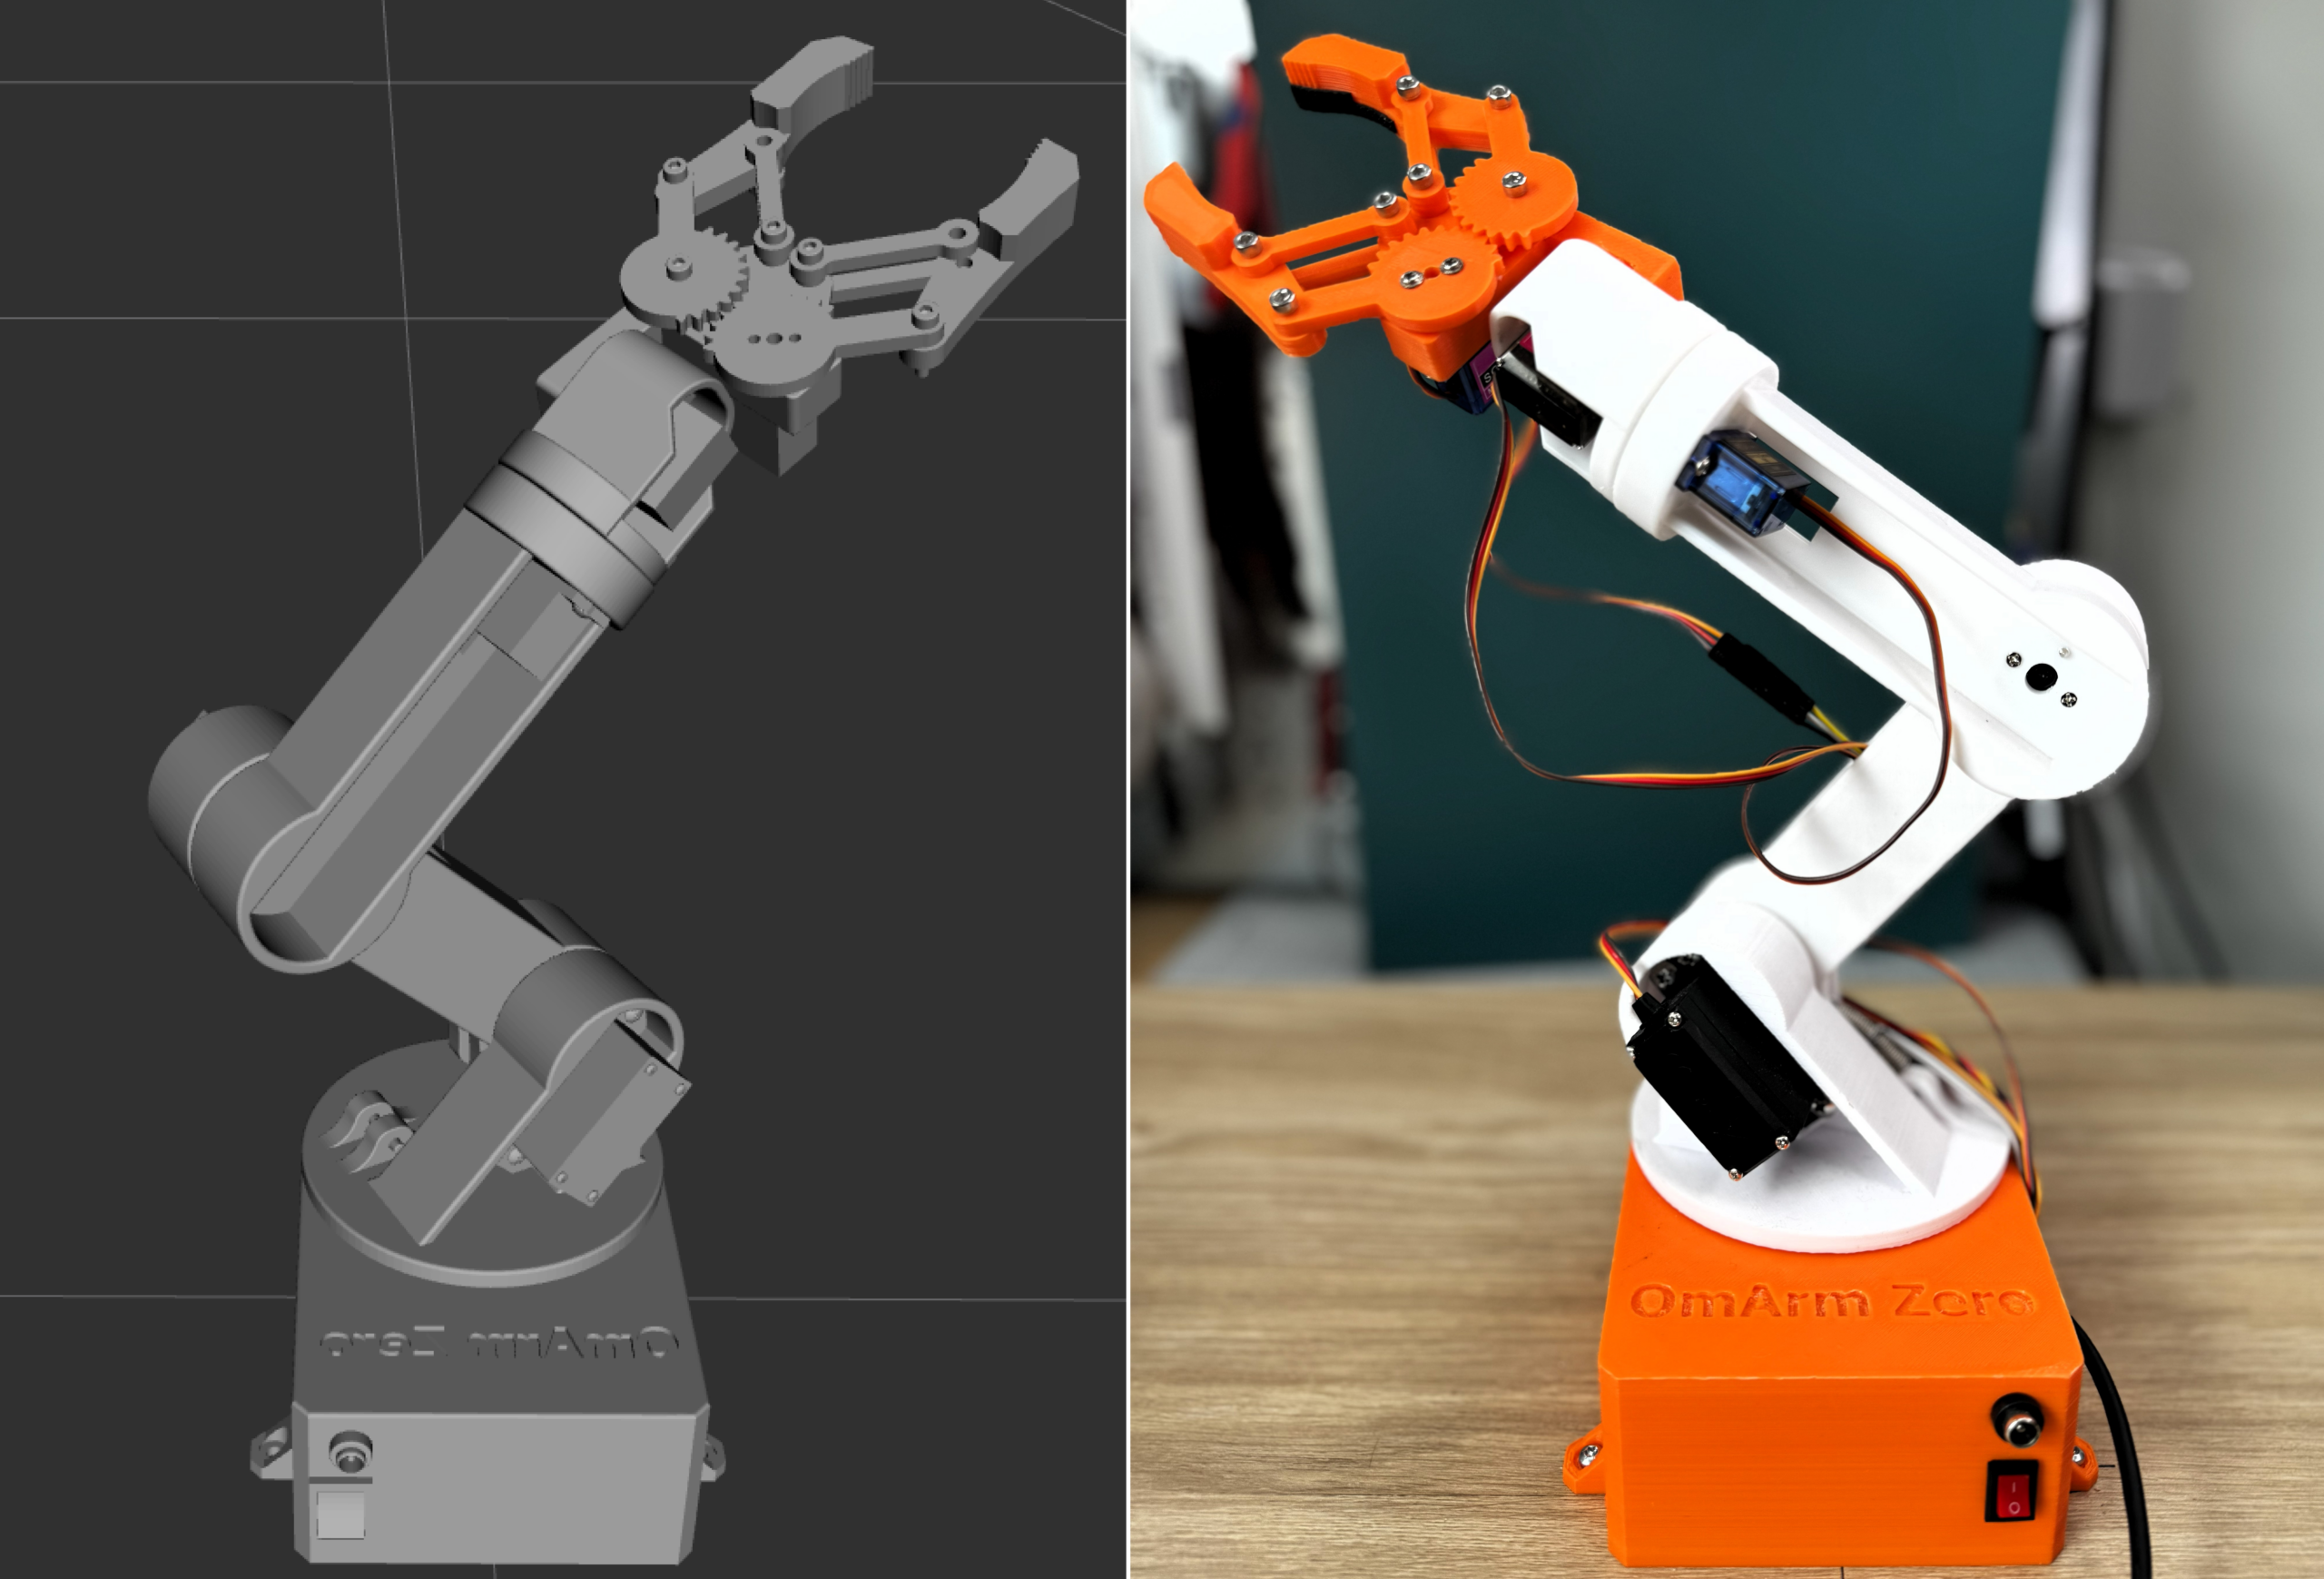
The real 3D printed OmArm One robot arm on a workbench beside the same arm rendered in RViz, both in the same pose

صدّر ملف URDF من Fusion 360، وراجعه، وصحّح اتجاهات المفاصل ونقاط الصفر والحدود حتى يطابق النموذج ذراع OmArm One الحقيقية، ثم شغّله في RViz وGazebo Harmonic. الجزء 2 من سلسلة OmArm One، لـ ROS 2 Jazzy.

قيادة ذراع روبوتية مطبوعة بتقنية ثلاثية الأبعاد (3D) بوحدة تحكم PS3: ESP32 وبلوتوث ودون حاسوب (OmArm One، الجزء 1.5)

A DualShock 3 controller held in one hand with the 3D printed OmArm One robot arm behind it holding an orange cube

اربط يد تحكم PS3 بـESP32 عبر Bluepad32 وحرّك ذراعًا روبوتية مطبوعة بالطباعة ثلاثية الأبعاد (3D) بسبع درجات حرية (7-DOF، أي 6+1 للقابض): عصوان للتحكم بالسرعة، وأربعة مستويات للسرعة، وتسلسل وضعيات مسجَّل، وإيقاف يبقى مثبتًا، دون الحاجة إلى أي حاسوب.

OmArm One: بناء ذراع روبوتية بسبع درجات حرية (7-DOF) بالطباعة ثلاثية الأبعاد (3D) على محامل كروية حقيقية (الجزء 1)

OmArm One, a 6-joint printed arm with a parallel-jaw gripper, rendered from the CAD assembly

ابنِ ذراعًا روبوتية مطبوعة بطابعة ثلاثية الأبعاد بسبع درجات حرية (7 DOF) تدور على محامل كروية حقيقية: مدى وصول 485 mm، وحمولة 200 g، وقائمة مواد (BOM) كاملة، و16 رسمًا متحركًا للتجميع، وتحكم عبر الويب بلوحة ESP32.

الالتقاط والوضع بالرؤية الحاسوبية: ذراعك الروبوتية تجد الأجسام وتمسكها وتنقلها (الجزء 4)

OmArm Zero grasping a marked cube on the table with overhead camera and ArUco markers

الجزء 4 من سلسلة OmArm Zero: عايِر كاميرا ويب USB، واكتشف علامات ArUco، ودَع الذراع تعثر على مكعب وتمسكه وتنقله باستخدام ROS 2 وMoveIt 2، في Gazebo وعلى الذراع الحقيقية.

شرح MoveIt 2: تخطيط الحركة والتحكم في الروبوت الحقيقي لذراع بست درجات حرية (6-DOF)

OmArm Zero robot arm with MoveIt 2 motion planning visualization in RViz

الجزء 3 من سلسلة OmArm Zero: اضبط MoveIt 2 للذراع بست درجات حرية (6-DOF، أي 5+1 للقابض)، وخطّط حركات خالية من التصادم في RViz، ونفّذها على ذراع ESP32 الحقيقية عبر جسر تسلسلي (Serial Bridge).

شرح URDF في ROS 2: عرض ذراع روبوتية ومحاكاتها في RViz وGazebo

ابنِ توأمًا رقميًا للذراع الروبوتية OmArm Zero: صِفها بصيغة URDF/Xacro، وافحصها في RViz، وحاكِها فيزيائيًا في Gazebo Harmonic على ROS 2 Jazzy.

OmArm Zero: بناء ذراع روبوتية بست درجات حرية 6-DOF (5+1 للقابض) مع تحكم عبر الويب باستخدام ESP32

OmArm Zero ESP32 robotic arm with browser-based web control interface

ابنِ OmArm Zero، ذراعًا روبوتية بست درجات حرية (6-DOF، أي 5+1 للقابض) يُتحكَّم بها عبر واي فاي (Wi-Fi) بواسطة ESP32. دليل بناء كامل مع ملفات الطباعة ثلاثية الأبعاد (3D)، ومخططات التوصيل، والبرنامج الثابت (Firmware)، وواجهة تحكم تعمل في المتصفح. مدى وصول 303 mm، وحمولة 100 g (وحتى 150 g مع نابض الكتف)، بتكلفة أقل من $50.

OmObiArm: بناء روبوت متحرك بذراع روبوتية مدمجة باستخدام Arduino مع التحكم عبر البلوتوث

Mobile robot arm OmObiArm with an orange gripper and four wheels on a white chassis, Bluetooth-controlled and designed using Arduino.

قم ببناء OmObiArm، وهو ذراع روبوت متنقل يمكن التحكم فيه عن طريق البلوتوث ومدعوم من Arduino Mega وHC-05 وAdafruit Motor Shield وPCA9685 servo driver. برنامج تعليمي كامل يغطي التصميم ثلاثي الأبعاد، والتجميع، والأسلاك، وكود Arduino، وتطبيق MIT App Inventor، والمعايرة، واستكشاف الأخطاء وإصلاحها، والأسئلة الشائعة.