OmArm One: Build a 3D Printed 7-DOF Robot Arm on Real Ball Bearings (Part 1)
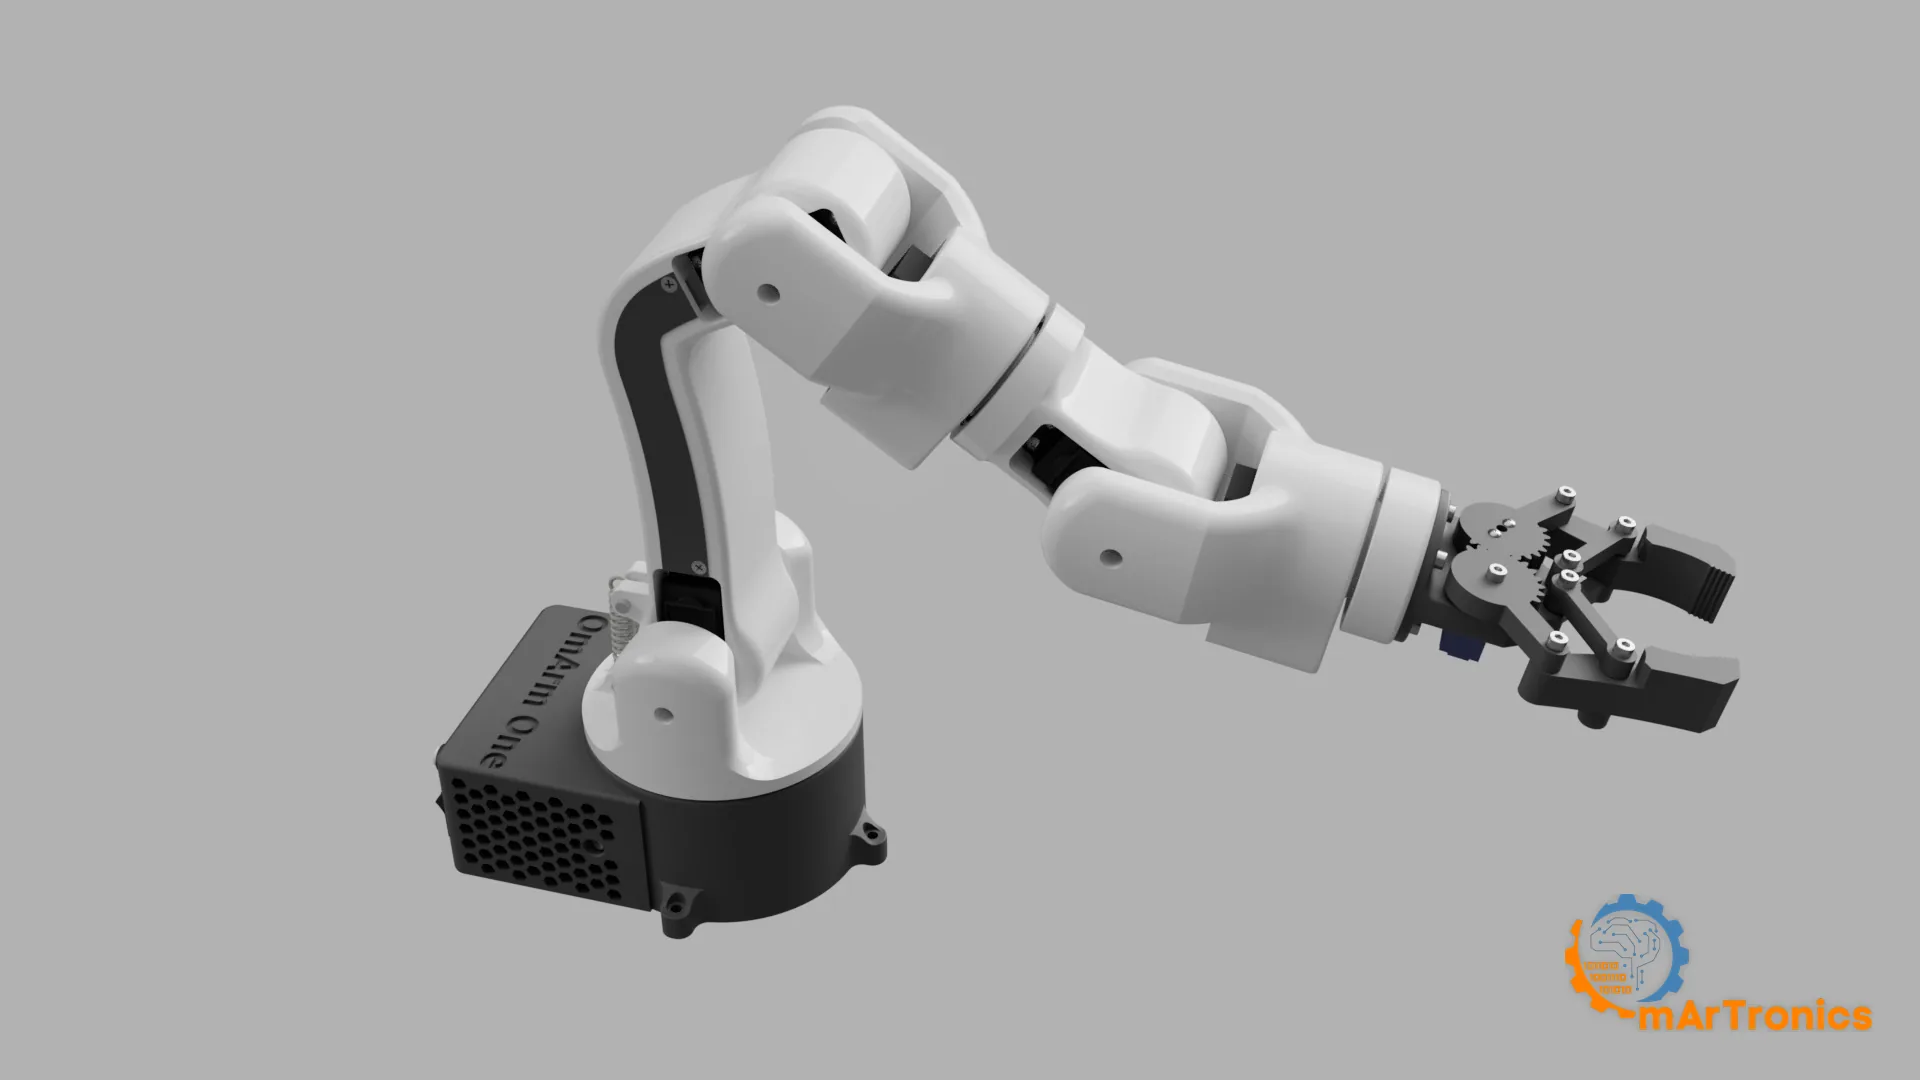
Build a 3D printed robot arm with 7 DOF on real ball bearings: 485 mm reach, 200 g payload, full BOM, 16 assembly animations and ESP32 web control.
Build a 3D printed robot arm with 7 DOF on real ball bearings: 485 mm reach, 200 g payload, full BOM, 16 assembly animations and ESP32 web control.
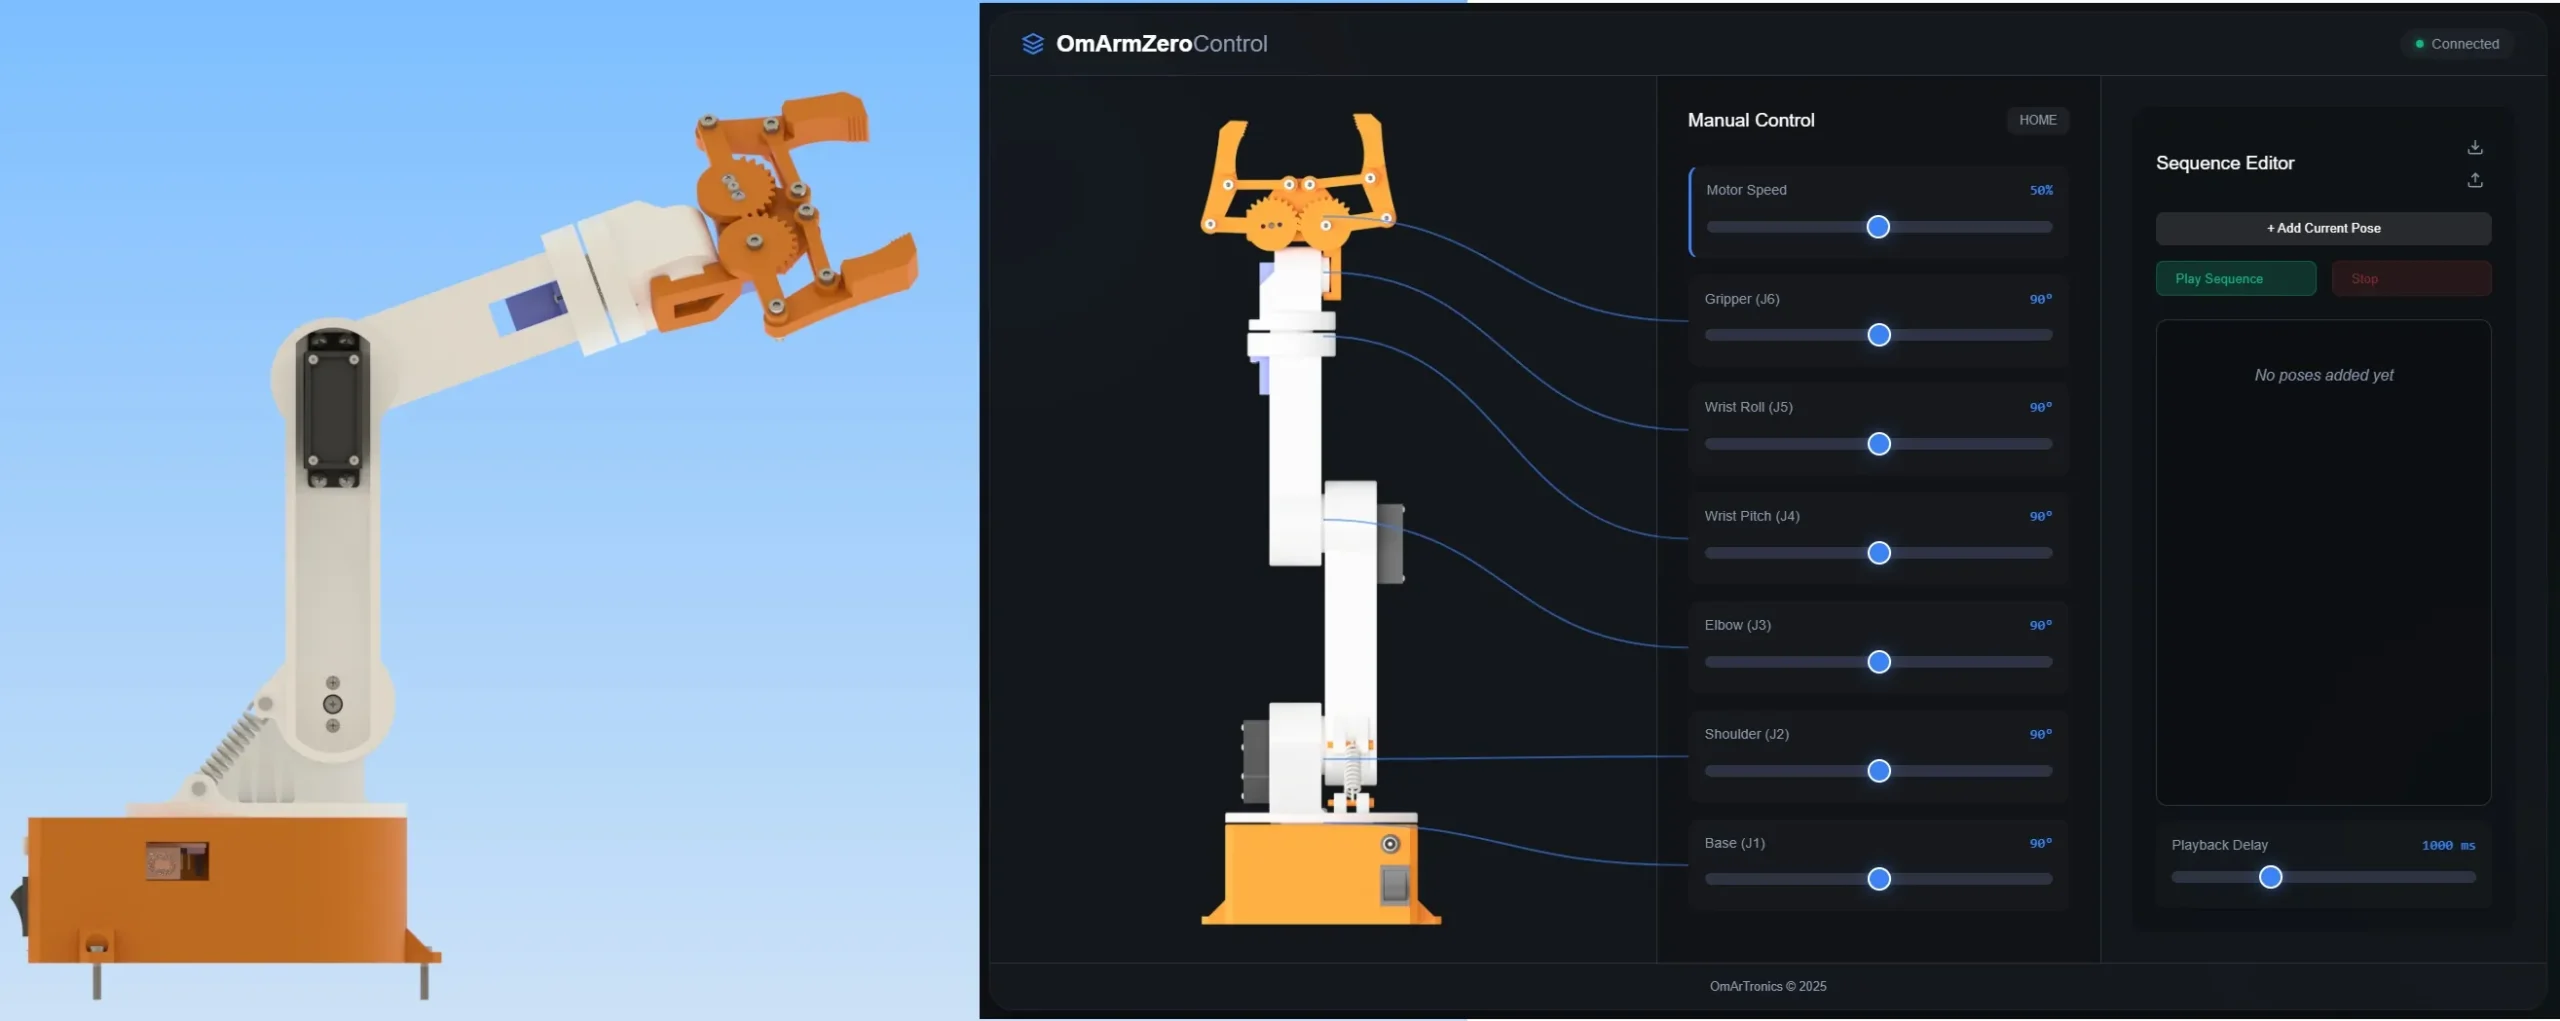
Build OmArm Zero, a 6-DOF (5+1 gripper) robotic arm with ESP32 WiFi control. Complete build guide with 3D printing files, wiring diagrams, firmware, and a browser-based control interface. 303mm reach, 150g payload, under $50.
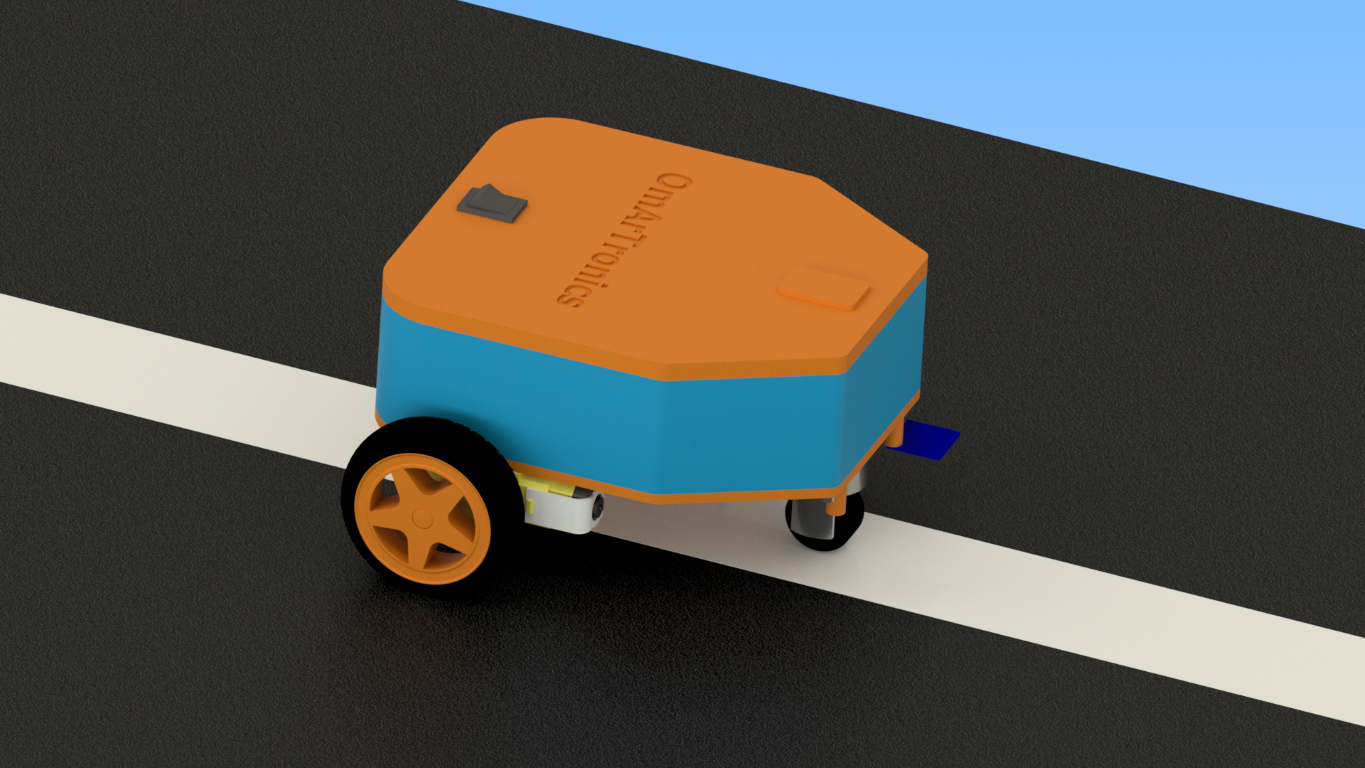
Complete tutorial for building an advanced TCS34725 line-following robot with Arduino and PID control. Covers 3D chassis design, wiring, sensor calibration, PID tuning, and full code walkthrough. The natural upgrade from the beginner KY-033 line follower project.
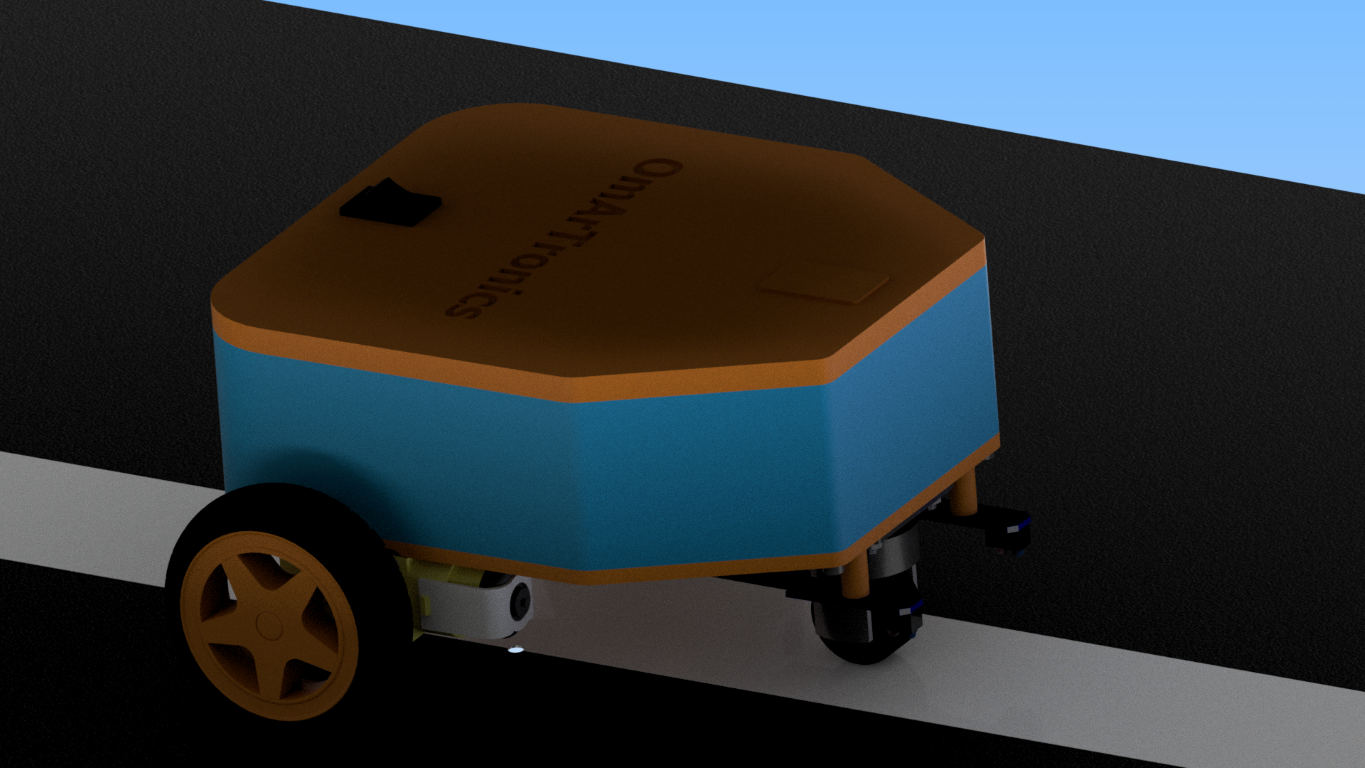
Learn how to build a KY-033 line following robot with Arduino from scratch. This beginner tutorial covers 3D design, assembly, wiring, Arduino code, testing, tuning, and troubleshooting for a complete DIY line follower robot project.
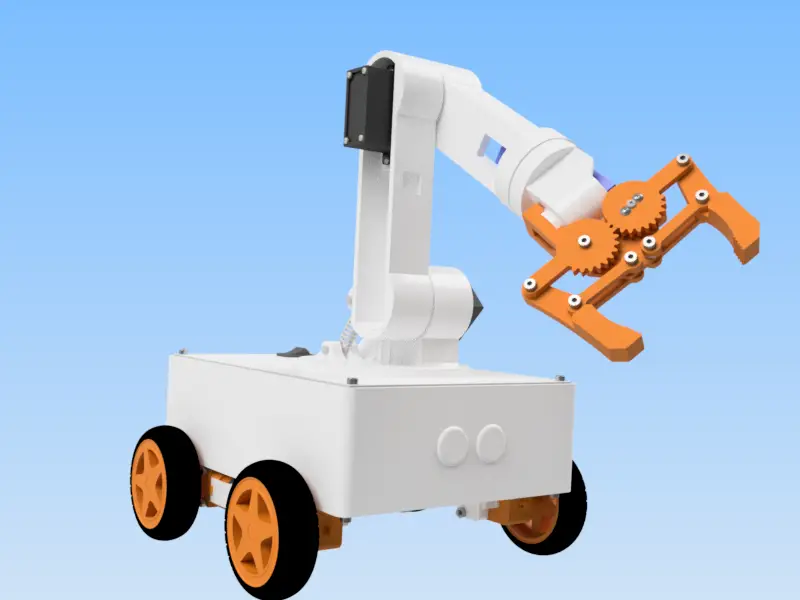
Build OmObiArm, a DIY Bluetooth-controlled mobile robot arm powered by Arduino Mega, HC-05, Adafruit Motor Shield, and PCA9685 servo driver. Complete tutorial covering 3D design, assembly, wiring, Arduino code, MIT App Inventor app, calibration, troubleshooting, and FAQ.
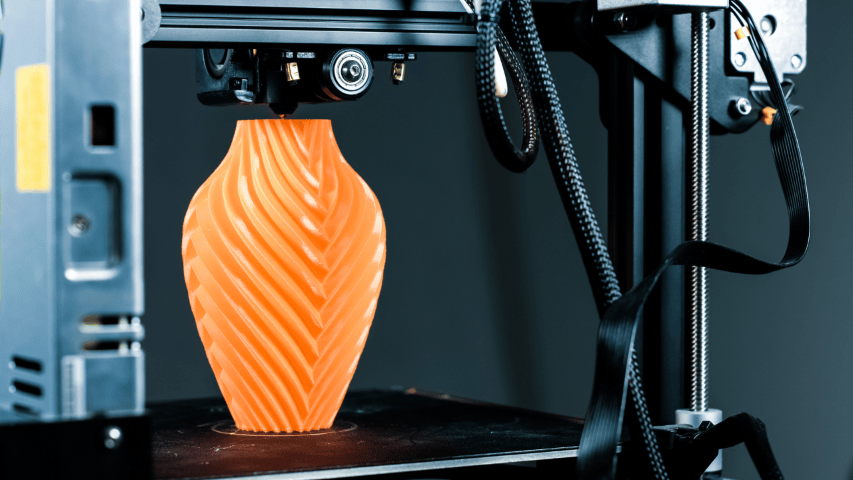
A complete beginner guide to 3D printing basics covering FDM technology, materials, the CAD-to-print workflow with Autodesk Inventor and Cura slicer, printer setup, troubleshooting, and practical project ideas for makers and engineers.