HC-SR04 Ultrasonic Distance Sensor with ESP32: How It Works, Wiring, and a Live Web Dashboard
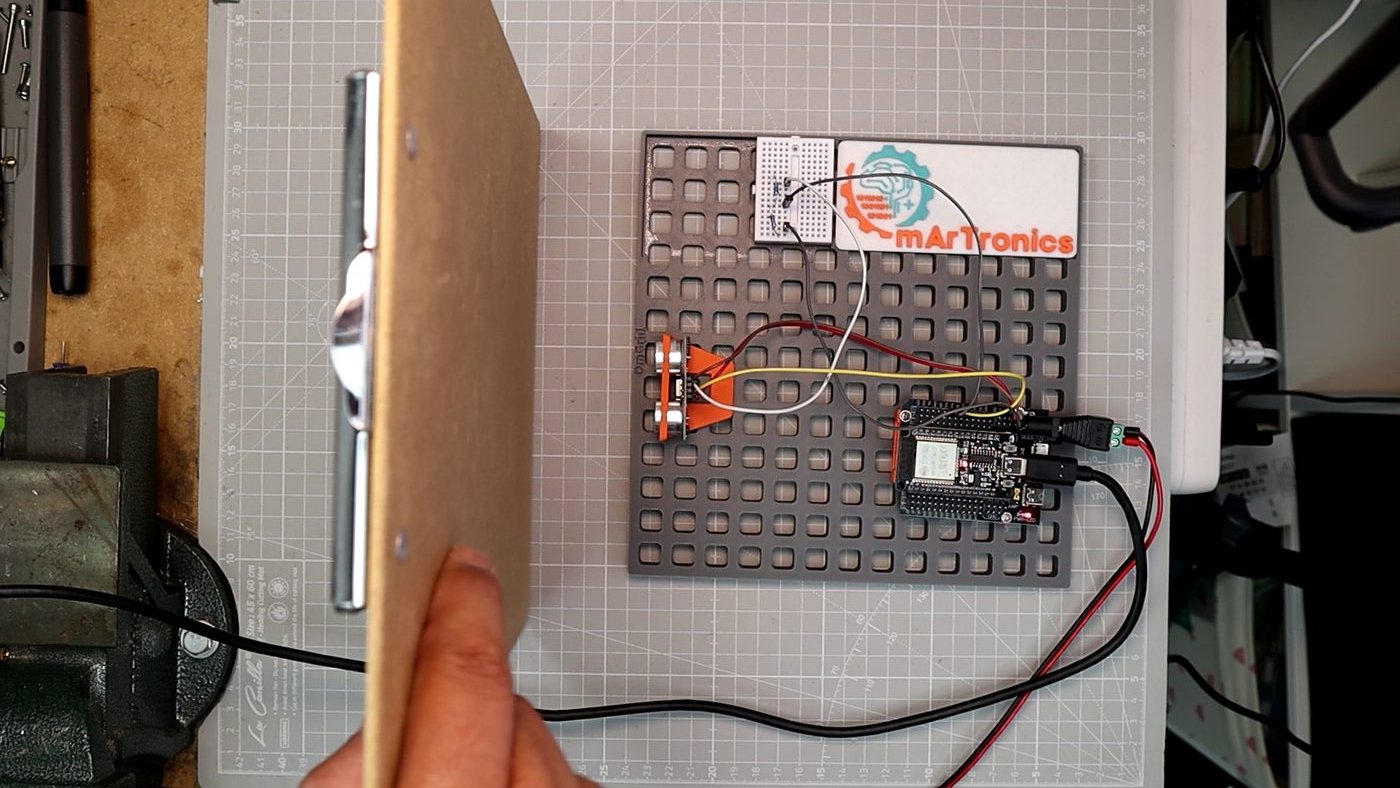
Wire an HC-SR04 to an ESP32, read distance over Serial, then serve a live dashboard from the chip in one upload. Includes measured jitter and range data.
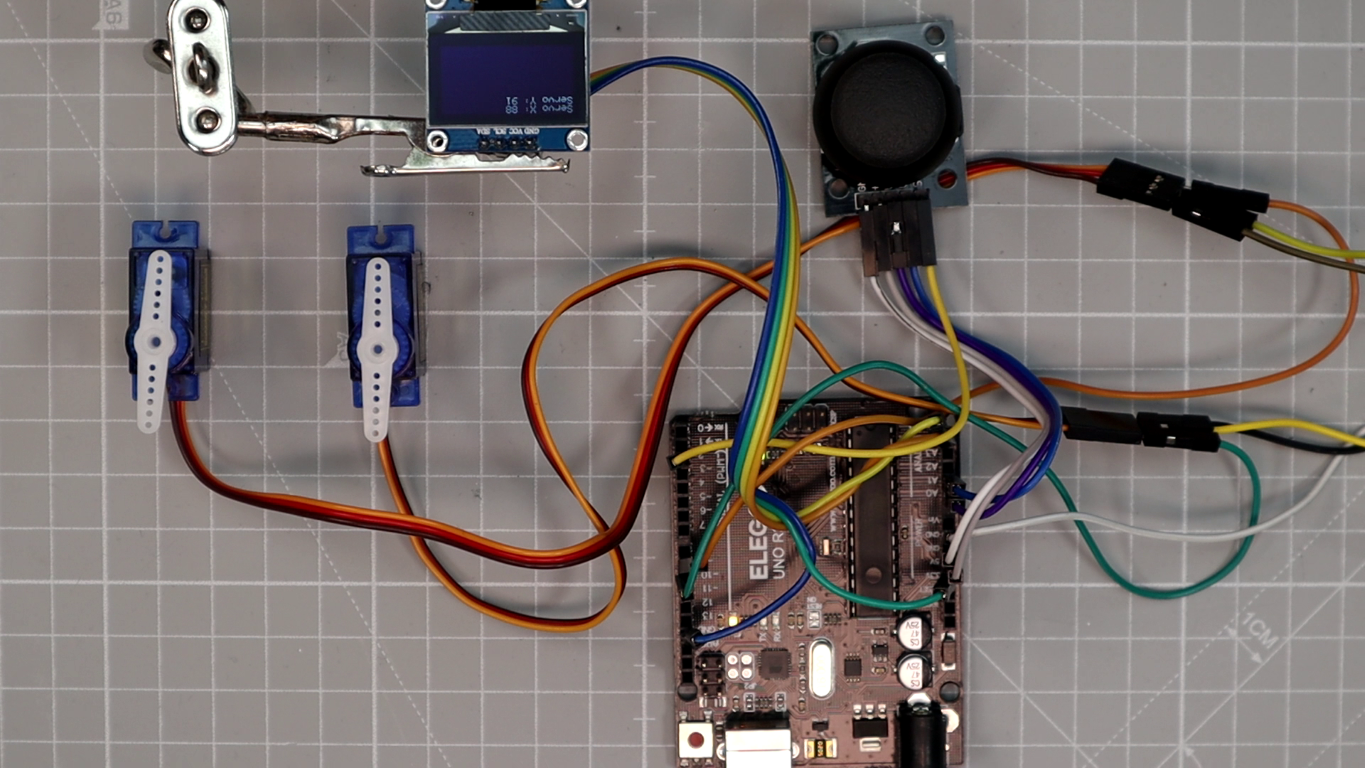
Learn how to control two servo motors with a joystick and SSD1306 OLED display using Arduino. Complete beginner tutorial with wiring diagram, full code, code explanation, calibration tips, troubleshooting, and FAQ.
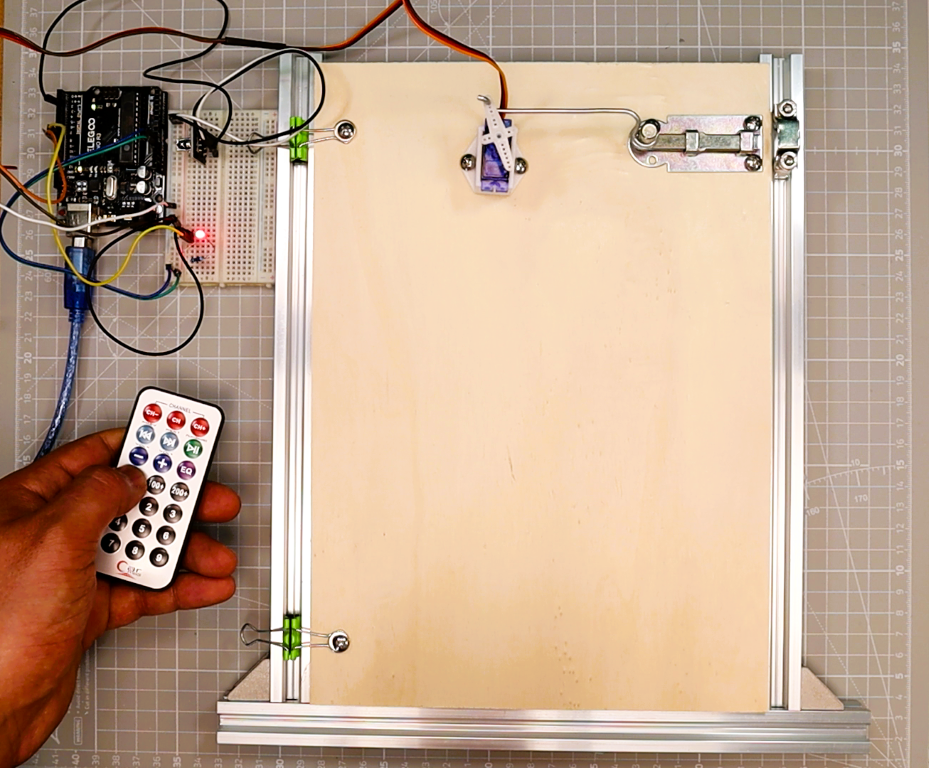
Build an Arduino IR remote LED controller with a KY-022 receiver, then upgrade the same circuit to operate a servo-driven door. Includes wiring diagrams, IR scanner code, complete Arduino sketches, troubleshooting, and FAQ.
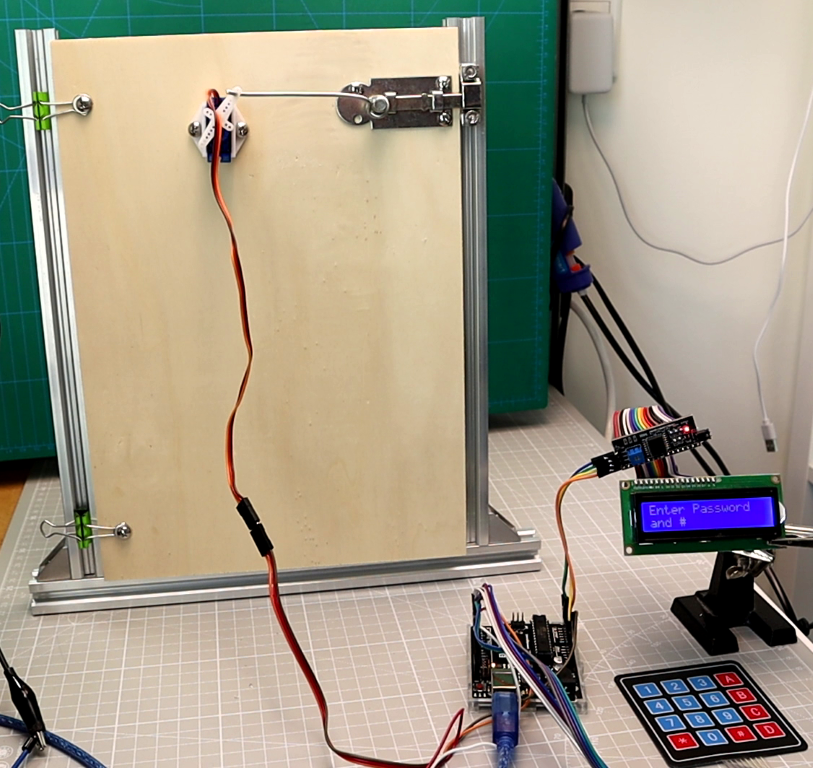
Step-by-step tutorial for building an Arduino password door lock using a 4×4 keypad, 16×2 I2C LCD display, and SG90 servo motor. Includes full wiring diagram, complete Arduino code, line-by-line code breakdown, testing tips, troubleshooting guide, FAQ, and upgrade ideas.
Complete tutorial for building an advanced TCS34725 line-following robot with Arduino and PID control. Covers 3D chassis design, wiring, sensor calibration, PID tuning, and full code walkthrough. The natural upgrade from the beginner KY-033 line follower project.
Learn how to build a KY-033 line following robot with Arduino from scratch. This beginner tutorial covers 3D design, assembly, wiring, Arduino code, testing, tuning, and troubleshooting for a complete DIY line follower robot project.
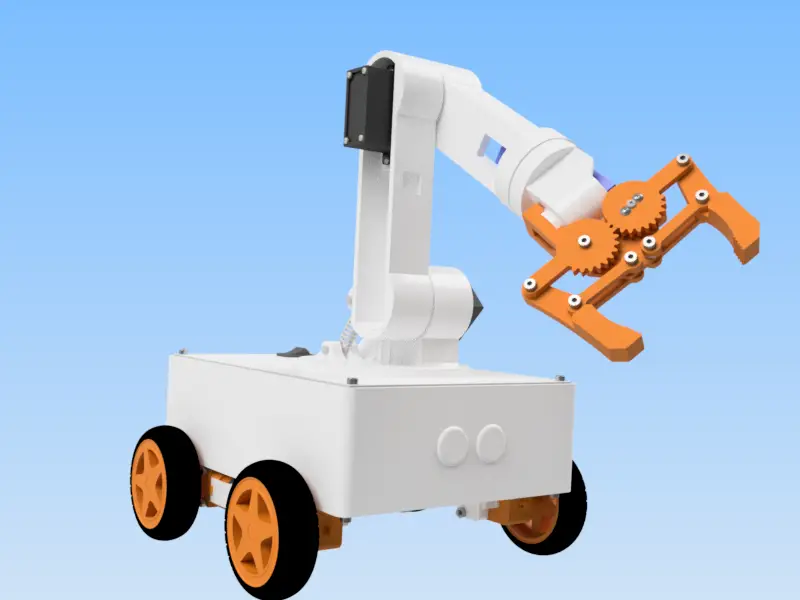
Build OmObiArm, a DIY Bluetooth-controlled mobile robot arm powered by Arduino Mega, HC-05, Adafruit Motor Shield, and PCA9685 servo driver. Complete tutorial covering 3D design, assembly, wiring, Arduino code, MIT App Inventor app, calibration, troubleshooting, and FAQ.
This tutorial walks through the HC-05 and HC-06 Bluetooth modules with Arduino. You’ll wire up the module, control an LED over Bluetooth, build a basic app in MIT App Inventor, and then take it further with relay-based lamp control. I also cover the common issues people run into and a few frequently asked questions.
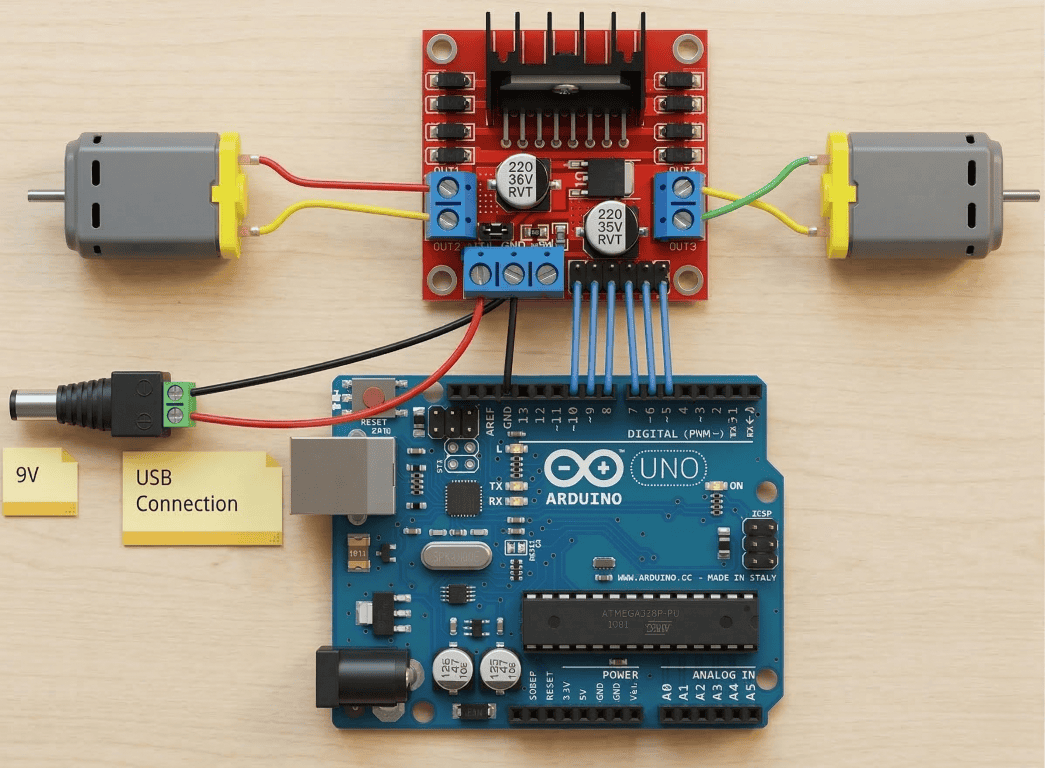
The L298N is a dual H-bridge motor driver, and it is one of the most common ways to control DC motors with an Arduino. Here I go through the pinout, how to wire it up, how PWM speed control actually works, and how to set motor direction in code. There is also a troubleshooting section for the issues that tend to come up.
Build a complete Arduino radar system using an HC-SR04 ultrasonic sensor and servo motor. This step-by-step tutorial covers wiring, Arduino code, optional buzzer alerts, and real-time Processing visualization. Includes troubleshooting, calibration tips, and FAQ.