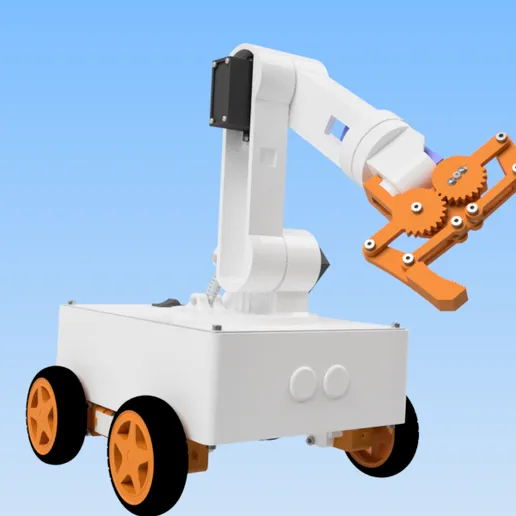
OmObiArm: Mobile Robot Arm with Arduino & Bluetooth – 3D Print and CAD Files (STL + STP)
7,90 €Launch price until 30 Nov 2026, then 19,90 €
A mobile robot arm that drives and grabs. The package holds the STL and STP files; the Arduino code and the wiring guide are in the free tutorial.
Digital download, nothing is shipped. No VAT charged (small business, § 19 UStG).
Personal-use license: build and print for yourself; no sharing of the files and no selling of files or printed parts. License details
Description
OmObiArm: mobile robot arm
The OmObiArm is a mobile robot with a robotic arm mounted on top. Think of it as the OmObi robot car with a 6-DOF arm bolted to the chassis. You drive it around over Bluetooth and control the arm at the same time.
The base is the four-wheel OmObi platform: four geared DC motors on the Adafruit Motor Shield V1.2 (L293D). The arm sits on a rotating platform and has the same joint layout as the standalone robotic arm: 5 axes plus a gripper, running on MG996R and SG90 servos. Everything runs on an Arduino Mega 2560. The sketch would also fit an Uno, but the Mega has 8 KB of SRAM instead of 2 KB and a second hardware serial port (Serial1), so the HC-05 can stay connected while you upload. Power comes from a 7.4 V 2S LiPo with an LM2596 step-down to 6 V for the servos.
How it works
An Adafruit Motor Shield V1.2 (L293D) handles the DC drive motors. The arm servos connect to a PCA9685 PWM driver over I2C. An HC-05 Bluetooth module handles wireless communication. You send commands from the OmObiArmControl app (MIT App Inventor, project file on GitHub), and the Arduino parses them to either drive the wheels or move a specific servo.
Driving and arm commands share one Bluetooth link and one loop. While a servo moves, the sketch reads no new commands, so a rover that is already driving keeps driving until the servo arrives (up to about 4.5 s for a full sweep). During pose playback the sketch ignores drive commands, so the rover stays put while the arm works.
Printing the parts
This is a bigger print job than the other projects. The chassis, arm brackets, and platform add up to about 30 to 35 hours of print time, depending on your settings. I recommend PLA with 30% infill for structural parts. The package holds two sets: the 13 arm parts (the base is modified to sit on the rover) and the six OmObi rover parts.
STP files are also included if you want to modify the design in your own CAD software.
Assembly notes
Wiring this one takes patience since there are more connections than the standalone arm or the basic robot car. The wiring tables in the tutorial cover every connection; add the 1 kΩ/2 kΩ divider on the HC-05 RXD line, which the diagram leaves out. Budget about two to three hours for the full assembly once everything is printed.
What’s included
- STL and STP design files for all parts
- Arduino code, wiring diagram and parts list: in the free step-by-step tutorial (link below)
Full tutorial: OmObiArm: Mobile Robot Arm with Bluetooth
Only logged in customers who have purchased this product may leave a review.
Related products
-
OmArm Zero: 6-DOF (5+1 Gripper) ESP32 Robotic Arm – CAD Files, Firmware, Presentation & Build Guide
7,90 € Add to cart -
OmObi Bluetooth Robot Car: Arduino, HC-05 & Motor Shield – 3D Print Files (STL)
Free Add to cart -
Advanced Autonomous Robot Car (Arduino Mega) – 3D Print Files (STL)
Free Add to cart -
OmArm Zero: ROS 2 Workspace for the 6-DOF (5+1 Gripper) Arm – URDF, MoveIt 2, Computer Vision, PDF Guides & Slides (Parts 2-4)
19,00 € Add to cart
Reviews
There are no reviews yet.